

Feed aggregator
Nuvoton Launches NuMicro M3351 5V MCU Series for Robotics and Industrial Automation
Nuvoton Technology Corporation, a leading global semiconductor supplier, has introduced the NuMicro M3351 series of 32-bit microcontrollers, featuring an Arm Cortex-M33 core operating at up to 144 MHz and a wide operating voltage range of 2.7 V to 5.5 V. The M3351 series provides a highly integrated 5 V MCU platform for smart appliances, industrial automation, and next generation robotic control.
High-Performance Cortex-M33 Core and Flexible Memory ConfigurationThe NuMicro M3351 series integrates a comprehensive DSP instruction set and a single-precision floating-point unit (FPU), improving execution efficiency for motor control, real-time signal processing, and complex control algorithms. The series offers 256 KB to 1 MB of Flash memory and up to 128 KB of on-chip SRAM. Devices with up to 1 MB of Flash support Dual-Bank operation, ECC, background operation, and Bank Swap, enabling a more flexible and reliable architecture for firmware-over the-air (FOTA) updates.
Select devices also provide up to 64 KB of independent Data Flash with endurance of up to 100,000 program/erase cycles. During Data Flash programming, the MCU can continue executing code from APROM, reducing the impact of parameter storage on real-time control and communication services. By separating firmware from frequently updated data, the system can more efficiently manage calibration parameters, user settings, fault logs, and operating records while reducing the need to reserve APROM space for EEPROM emulation.
High-Resolution Analog Peripherals and Real-Time ControlThe M3351 series integrates a 12-bit SAR ADC with a sampling rate of up to 1.7 MSPS and a 14-bit SAR ADC operating at up to 1.0 MSPS with as many as 16 input channels. It also provides a 12-bit DAC, two analog comparators, up to 24 channels of 16 bit PWM/BPWM, and up to two enhanced quadrature encoder interfaces (EQEI).
Hardware trigger paths among the PWM, ADC, and analog comparator modules reduce CPU workload and improve real-time response, making the M3351 series well suited for closed-loop control applications such as motors, robotic joints, fans, pumps, valves, actuators, and power control systems.
Extensive Connectivity and Hardware-Based SecurityThe M3351 series provides up to two CAN FD interfaces, 10 UARTs, three I²C interfaces, as well as I3C, QSPI, SPI/I²S, USCI, and USB 2.0 Full-Speed Device/Host connectivity.
To address the growing security requirements of connected equipment, the series incorporates Arm TrustZone technology and Secure Boot with SHA-256 and ECDSA-P256 firmware authentication. Select models further integrate TRNG, PRNG, AES-256, SHA-512, and HMAC-SHA hardware functions to strengthen secure boot, firmware authentication, and data protection.
Industrial-Grade Reliability and Comprehensive Development SupportThe M3351 series supports an operating temperature range from -40°C to +105°C and provides robust immunity with ESD HBM protection up to 4 kV and EFT immunity up to 4.4 kV. Its wide 2.7V to 5.5V operating range allows direct operation in common 5V control environments, reducing voltage-conversion requirements and overall system design complexity.
The series is available in package options ranging from the compact QFN33 measuring 5 × 5 mm to the high-pin-count LQFP128 measuring 14 × 14 mm. Nuvoton also provides the NuMaker-M3351KJ development board and Nu-Link debugger, with support for Keil MDK Nuvoton Edition, IAR EWARM, and Visual Studio Code development environments, accelerating product development and deployment across robotics, smart appliances, motor and actuator control, and industrial automation applications.
The post Nuvoton Launches NuMicro M3351 5V MCU Series for Robotics and Industrial Automation appeared first on ELE Times.
Vicor to Showcase Power-Dense DC-DC Converters for Defence Applications at Land Forces 2026
Vicor will demonstrate how high-density power modules enable SWaP compatible power designs for defense applications at the Land Forces International Land Defence Exposition on October 6-8 in Perth, Australia.
Demands of rapid response are driving modern land defense innovation, where electrification is redefining the field mobility strategies and rules of engagement. To meet increasing system capabilities, defense power architecture is moving away from bulky custom subsystems toward a more interoperable, compact, modular building bloc approach.
Vicor enables this shift with high-density power solutions that drastically cut size and weight. Rugged power modules and VITA/SOSA-aligned supplies support the entire delivery network—from high-voltage inputs down to standard MIL-STD 270V and 28V buses. Vicor’s entire high performance portfolio of M-grade products are reliable, rugged and support SWaP specifications.
The post Vicor to Showcase Power-Dense DC-DC Converters for Defence Applications at Land Forces 2026 appeared first on ELE Times.
Laser Parking Assistant Using ToF Technology
Using a brand-new laser distance meter based on ToF technology, we are building a parking assistant for garages and car ports.
The garage space problemCars have grown over the years within the same segment, and while that has given occupants a level of comfort that was unthinkable in the small cars of thirty years ago, it has also forced many drivers to deal with garages and underground car parks that were built and sized for the vehicles of the past. It is not just a matter of width (parking spaces in Italy are often ridiculously small…) but also of length. So more than one driver lines the back wall of the garage with strips of soft material such as foam, because inevitably, to fit the whole car in, one time out of two they hit the back wall.
Electronics, which has shown it has a solution for everything, naturally has one for this problem too; we demonstrate it in this article, where we propose a measurement system based on ST Flight Sense (ToF) technology for proximity detection, implemented by a specific ST chip and fitted with an annular LED display that changes colour according to distance. Something, then, similar to the parking sensors fitted on cars, but this time fixed to the back wall of the parking space.
As we get closer, the LEDs light up green, then gradually turn yellow, then red, and as soon as the distance drops to the minimum they flash red, indicating that you must stop.
The time-of-flight principleTo achieve all this we use a very recent ST product, namely a laser distance meter that can be considered the evolution of the one described in the April 2017 issue, to which we refer anyone who wants to know the fundamentals and the theory of operation of sensors based on the time of flight (ToF) of laser pulses in detail.
To take a measurement, it sends a beam of light against the object or wall to be detected and picks up the reflection from it; this only works if the surface of the object or the wall does not absorb too much of what hits it. The measurement is based on counting the time taken by a pulse to travel from an emitter to the surface of the object to be detected and then back to the sensor; the distance (d) is determined as the product of the propagation speed of the pulse (v) and half of that time (t), according to the relation:
d = v x t/2
The speed of light in air is close to that in a vacuum: 300,000 km/s.
Response times and measurement accuracyThe measurement works like this: when the laser diode is powered, a counter is triggered and is stopped the moment the receiving device is excited by the radiation reflected from the object onto its sensor.
The time counted in this way is affected by the response time of the emitter (the time from when power is applied to when the radiation appears at the emitting surface) and by that of the receiving sensor (the time between when the photons making up the radiation hit the sensitive surface and when the corresponding electrical signal is registered). Another element that introduces tolerance into the measurement is the latency of the counter and of the logic devices in between. Given the very short travel times of the light pulse, these times must be extremely small.
A useful method to limit the error (and so raise accuracy, especially at short distances) is to place a second light sensor facing the emitter (but without covering its emitting surface) so that it detects the light as it leaves; this compensates for both the response delay of the emitter and that of the sensor.
The VL53L0X sensorAfter this introduction let us get to the heart of the project, which consists of the VL53L0X chip, mounted on a breakout board whose schematic we publish, interfaced with a microcontroller that in this specific case is the one on the tiny and essential Beetle; to complete the project we have a ring of NeoPixel LEDs, which will let us give the visual indications required, lighting up in the colour corresponding to the distance detected.
ST FlightSense technologyBefore looking at the complete system, let us spend a moment on the breakout board containing the distance sensor and on the sensor itself, which allows measurements up to 2 m with an accuracy of a few mm. Our sensor, which is based on ST FlightSense technology, integrates in a single SMD package a Photon Avalanche Diode (SPAD) array light sensor, a traditional high-sensitivity ambient light sensor (ALS = Ambient Light Sensor, from 1 Lux to 100,000 Lux) and a class 1 laser diode emitter of the Vertical Cavity Surface-Emitting Laser (VCSEL) type operating at a wavelength of 940 nm, so in the deep infrared.
Independence from the reflection coefficientThe sensor architecture is such that measurements and detections are practically independent of the light reflection coefficient of the surface to be detected, thanks to special circuitry that allows the gain of the receiving stage and the ambient light to be adjusted and very short pulses to be emitted.
On the light sensor side (see Fig. 1) the device incorporates a second light detector that serves to determine the brightness of the environment, so as to obtain a signal that is subtracted, because it is uniform, from the pulse signal coming from the return of the reflected laser pulse; in this way the amplitude of the resulting signal faithfully reflects the distance.
 Fig. 1 The ST sensor chip: on the left you see the block diagram, while the figure on the right highlights, next to the window for the light detector (the lower one), the opening that faces the ambient light sensor.
In other words, it is easy to discriminate the ambient brightness by knowing when the light pulses start and waiting for their arrival, while ambient light is fairly constant.
Emission and reception geometryFig. 2 shows how the sensor works: the pink cone represents the IR light emitted by the laser and in green we see the reception cone of the sensor, with the relevant aperture angles; we note that the reception angle of the photosensor is clearly greater than the emission angle of the laser, which ideally should be zero, since the best solution would be to emit a beam that does not spread, collimated to infinity. In practice a conical beam makes it easier to detect objects, especially small ones.
 Fig. 2 Structure of the ST sensor: the cone of light emitted by the LED is narrower than the aperture of the SPAD sensor.
Eliminating the reflected light is essential in this case, not so much because of the level of disturbance it superimposes on the return signal, but rather for the calculation of the time of flight of the light pulse, since the wave reflected inside the glass would arrive before the light reflected by the object whose distance is being measured, causing a measurement error on the low side (the measured distance would be shorter).
Detection with the VL53L0XLet us now see, with the help of Fig. 3, how detection by the VL53L0X takes place: the laser diode (Emitter) emits periodic light pulses, part of which is reflected by the Target Object (the object or wall whose distance is to be measured) and returns to the sensor; by synchronising the emission with the waiting for the pulses, it is possible to remove the disturbance caused by ambient brightness, raising the sensitivity of the device. The substantial difference between the VL53L0X and typical IR proximity meters is that the latter are based on the intensity of the reflected wave, which makes them unreliable because it depends on the reflection coefficient of the surface of the object to be detected.
 Fig. 3 Schematic of how the VL53L0X family of devices works.
The peculiarity of the detector diode, that is the Single Photon Avalanche Diode, is that it works in reverse bias in the portion of its characteristic corresponding to the onset of the avalanche effect: keeping the diode at an anode-cathode voltage close to the breakdown voltage, when the surface is struck by light, the first photon of that light triggers conduction by avalanche effect and the current increases sharply, then drops to zero when the voltage falls below the breakdown voltage. At this point another photon is needed to trigger conduction. By arranging an array of these diodes it is possible to count photons.
Schematic of the breakout board Schematic of the breakout board built around the VL53L0X sensor.
Let us now take a look at the breakout board containing the VL53L0X sensor, where besides the chip we find a low drop-out linear voltage regulator (U1) and a MOSFET adapter for the I²C-Bus interface, useful for shifting the 0/2.8 V logic levels of the chip to adapt them to the standard TTL levels of boards with traditional logic and of Arduino.
The I²C level shifterTo explain how the shifter works, let’s start with the clock, which on the U2 side is routed to the line of pin 10, while towards the connection pin-strip it is tied to SCL (both lines have a pull-up resistor): when the SCL of the connector is at a logic high level, the protection diode inside the MOSFET (placed between drain and source) is reverse biased because the source is negative (it sits at 2.8 volts) with respect to the drain (which is held at 5 volts by R5), and even though the pulse does not reach the SCL of U2, the latter is at logic 1. Conversely, when the SCL contact of the pin-strip is at logic zero (0 V), the MOSFET is still off (because its gate is biased at 2.8 volts) but its protection diode conducts, since the source is at 2.8 V while the cathode is at zero, so the low level on SCL pulls pin 10 of the VL53L0X down to logic zero (0.6 V to be exact). The SCL channel is unidirectional, so the opposite situation does not arise, that is, U2 receives the clock from the host.
Let’s move on to SDA, analysing the case where the host is sending data: when SDA is at logic zero, the protection diode of Q2 conducts and pulls the source, and with it pin 9 of U2, down to 0.6 V; on the other hand, when it is at 5 volts, both the MOSFET and the diode are off, so the SDA of the VL53L0X is brought to 2.8 V (high level) by the pull-up resistor R7.
If instead it is U2 that is transmitting, when it brings its own pin 9 to logic zero the MOSFET Q2 conducts between drain and source, because its source is at zero volts while the gate is at 2.8 V, so its drain current pulls the SDA of the connector down to about 0 V, due to the drop across the pull-up resistor R6; conversely, when pin 9 of U1 is at a high level (2.8 V) the source and gate are at the same potential and the MOSFET stays off, letting the pull-up resistor R6 hold the SDA line going to the pin-strip at logic 1 (but at 5 volts).
The voltage regulatorAs for the voltage regulator, it is a MIC5504-2.8YM5-TR from Micrel, that is, an LDO with a 2.8 V output (supplied at the input between 2.5 and 5 V) capable of delivering 500 mA of current, packaged in a SOT-23 case and with a minimum voltage drop of 160 millivolts between the IN and OUT pins; it is very stable over temperature and integrates short-circuit protection at the output and over-temperature protection, as well as input reverse-polarity protection.
The chip can be put into shutdown by bringing its EN pin to logic zero.
I²C communication and GPIO configurationCommunication with the host device, typically a microcontroller, takes place over the I²C-Bus formed by the SCL (5) and SDA (6) pins, respectively the clock and the bidirectional data channel; through the bus (which runs at 400 kHz) it is possible to set operating modes, sensitivity and so on, but also to read the measurement result. Regarding operating modes, it should be said that the device can take a measurement at a settable rate, or on request (a mode that helps optimise consumption, which comes largely from switching on the laser).
Before concluding the description of the schematic, let’s spend a moment on the GPIOs of the VL53L0X, which can be configured through specific commands sent over the I²C-Bus; the setting for our project is contained in the dedicated library that can be downloaded together with the other project files. In it:
- GPIO0: changes state when acquisition is complete and can be used to tell the Host microcontroller that it can read the measurement;
- GPIO1, if brought to GND, puts the ST device into standby; once it is in that condition, U1 can be reactivated by sending it again over the I²C-Bus the configuration required for the measurement (so simply bringing the GPIO back to a high level is not enough).
The VL53L0X is powered through the AVDD (positive) and GND (ground) pins for the receiving section and AVDD_VCSEL and AVSS-VCSEL for the laser diode.
The VL53L0X management library can be downloaded, along with the other project files, from https://github.com/pololu/vl53l0x-arduino. To use it, after downloading it you must copy the folder contained in the .zip file into the “libraries” directory where the Arduino environment is installed. The same goes for the library that manages the Neopixel ring.
The parking assistantWell, now that you know everything about the breakout board, let’s see, with reference to the wiring diagram, how our system was built. The small Beetle is enough for us because we only use four I/Os, namely two for the I²C-Bus with which the little Arduino talks to the breakout board and one for the data channel needed to drive the neopixel ring, which specifically is a RING16NEOPIXEL, made up of 16 RGB neopixel LEDs (we have already used these special “smart” LEDs several times in the past). Everything is powered by the voltage applied to the Beetle.
The firmwareAs for the firmware side, the project is managed with the sketch (VL53L0X_Garage_v2), the most relevant portion of which you will find in Listing 1; it loads the VL53L0X and neopixel ring management libraries, after initialising the serial connection, and then loads the I²C-Bus library to communicate with the breakout board, then starts polling the latter cyclically and listening for the corresponding data; the same sketch will send the data on the detected Lux and the distance from the object to the serial port opened for Arduino. The sketch also initialises the line (pin 11) used to drive the LED ring.
Note that the sensor has a default range of 1.2 metres; to raise it to the declared maximum of 2 metres you need to configure it with a dedicated command. It should also be considered that the two metres are reached indoors and not outdoors. The less light there is, the more accurate the reading will be, but that matters little to us because the system will normally be used in garages and in covered and underground car parks.
The sketch is written for a 16-LED ring, but there is nothing stopping you from using a larger one or several combined together: to do so you need to modify the statement #define PIXEL_COUNT 16.
The colour thresholdsWhen the vehicle enters, it is detected at a distance of at least 1.2 metres (the value set in the sketch) and the neopixel ring automatically lights up green, one LED at a time until all the LEDs are on. As the car gets closer to the wall (to the sensor), the colour of the light indicator changes accordingly; to be exact, the light is:
- green: between 120 and 60 cm;
- yellow: between 60 and 30 cm;
- red: between 30 and 15 cm;
- flashing red: below 15 cm.
From green to yellow light the LEDs fade out gradually.
If the vehicle stops, since the same position keeps being detected (the ring stays on the same colour), after a certain number of cycles (the MAX_ON variable in the sketch) the indicator turns off. Currently in the sketch the turn-off time is set to about 30 seconds, that is, “MAX_ON * (DELAY_CYCLE +100)” where 100 is a fixed delay present in the various cycles. As soon as a change in distance is detected, the firmware reactivates the system. This trick makes it possible to limit power consumption to what is strictly necessary.
Long Range and shutdownIt should be pointed out that the firmware is set up for the ranges given above, but for greater accuracy and to avoid false readings, the sensor’s Long Range mode (up to 2 metres) has not been enabled; this way the maximum range will be 1.2 m, but that is more than a valid value in a garage. If you wanted to enable Long Range, you would only need to remove the comment from the statement “#define LONG_RANGE” and then reload the firmware onto the board.
Note that the firmware provides for the possibility of managing the shutdown of the breakout board through the statement int pwrPin = 13, which sets pin 13 to act on the SHD line.
Listing 1#include <Wire.h> #include <VL53L0X.h> #include <Adafruit_NeoPixel.h> #define PIXEL_PIN 11 //Pin used to drive the NeoPixel #define PIXEL_COUNT 16 //Number of NeoPixels to manage //#define LONG_RANGE //Enable if you want the ToF to detect up to 2m //(not recommended in bright environments) instead of //1.2m (recommended for indoor use) VL53L0X sensor; Adafruit_NeoPixel strip = Adafruit_NeoPixel(PIXEL_COUNT, PIXEL_PIN, NEO_GRB + NEO_KHZ800);
int val_max = 60;//Brightness value (up to 255)
int distance = 0;//distance value read from the ToF
int num_R = 0; //Number of times the red colour turns on in the same range
int num_Y = 0; //Number of times the yellow colour turns on in the same range
int num_G = 0; //Number of times the green colour turns on in the same range
int num_led_on = 0; //Convenience variable used by some effects
//If the same colour stays active for MAX_ON cycles, the
//indicator turns off. The time is roughly defined by //MAX_ON * (DELAY_CYCLE + 100ms) (seconds)
int const MAX_ON = 200;
int const ALARM1 = 150; //Alarm threshold 1
int const ALARM2 = 300; //Alarm threshold 2
int const ALARM3 = 600; //Alarm threshold 3
int const ALARM4 = 900; //Alarm threshold 4
int const ALARM5 = 1200; //Alarm threshold 5
int const DELAY_CYCLE = 50; //Pause time in ms
int const DATO_OK = 4; //Number of readings that must be valid to
//turn the indicator on. It is needed to remove
//possible spikes caused by light
void setup()
{
strip.begin();
strip.show(); //Pixel initialisation
Serial.begin(9600);
Wire.begin();
sensor.init();
sensor.setTimeout(500);
#if defined LONG_RANGE
//lower the return signal rate limit (default is 0.25 MCPS)
sensor.setSignalRateLimit(0.2);
//increase laser pulse periods (defaults are 14 and 10 PCLKs)
sensor.setVcselPulsePeriod(VL53L0X::VcselPeriodPreRange, 18);
sensor.setVcselPulsePeriod(VL53L0X::VcselPeriodFinalRange, 14);
#endif
sensor.startContinuous();
}
void loop()
{
distance = sensor.readRangeContinuousMillimeters();
if (distance < ALARM1) //If distance is less than 15cm turn on the red colour
{
if (num_R<MAX_ON)
{
num_R=num_R+1;
num_Y=0;
num_G=0;
//Immediate turn-on because the obstacle is too close
Colore(1,2,distance,ALARM1,0);
}
}
//If distance is between 15cm and 30cm turn on the yellow colour
if ((distance > ALARM1) && (distance <= ALARM2)) {
if (num_R<MAX_ON)
{
num_R=num_R+1;
num_Y=0;
num_G=0;
//Turn the LED on only with a DATO_OK number of readings in the same range
if (num_R>=DATO_OK) Colore(1,1,distance,ALARM2,ALARM1);
}
}
//If distance is between 30cm and 60cm turn on the yellow colour
if ((distance > ALARM2) && (distance <= ALARM3))
{
if (num_Y<MAX_ON)
{
num_R=0;
num_Y=num_Y+1;
num_G=0;
if (num_Y>=DATO_OK) Colore(2,1,distance,ALARM3,ALARM2);
}
}
//If distance is between 60cm and 90cm turn on the green colour
if ((distance > ALARM3) && (distance <= ALARM5))
{
if (num_G<MAX_ON)
{
num_R=0;
num_Y=0;
num_G=num_G+1;
if (num_G>=DATO_OK) Colore(3,4,distance,ALARM5,ALARM3);
}
}
if (distance > ALARM5) //If distance is greater than ALARM5 turn the indicator off
{
num_R=0;
num_Y=0;
num_G=0;
Colore(0,1,distance,0,0);
}
if ((num_R>=MAX_ON) || (num_Y>=MAX_ON) || (num_G>=MAX_ON))
{
Colore(0,1,distance,8000,ALARM5);
}
if (sensor.timeoutOccurred()) { Serial.print(” TIMEOUT”); }
delay(DELAY_CYCLE);
}
//Sets the colour and the turn-on mode
void Colore(int col, int mode, int dist, int alarm_MAX, int alarm_MIN)
{
uint32_t R;
uint32_t G;
uint32_t B;
switch(col)
{
case 0: //All Off
R=0;
G=0;
B=0;
break;
case 1: //Red
R=val_max;
G=0;
B=0;
break;
case 2: //Yellow
R=val_max;
G=val_max/2;
B=0;
break;
case 3: //Green
R=0;
G=val_max;
B=0;
break;
}
switch(mode)
{
case 1:
num_led_on=0;
ColorOn(strip.Color(R, G, B)); //Steady on
break;
case 2:
num_led_on=0;
ColorBlink(strip.Color(R, G, B)); //Blinking colour
break;
case 3:
ColorCircleSingle(strip.Color(R, G, B)); //Cyclic turn-on
break;
case 4:
ColorDistance(strip.Color(R, G, B),dist,alarm_MAX,alarm_MIN);
break;
}
}
//Gradual turn-on of the colour based on the distance you are at
void ColorDistance(uint32_t c, int dist1, int almax, int almin)
{
double val1;
double val2;
uint16_t i;
val1=almax-almin;
val1=val1/PIXEL_COUNT;
val2=dist1-almin;
val2=almax-val2;
val2=val2-almin;
val2=val2/val1;
if (num_led_on==0)
{
for(i=0; i<strip.numPixels(); i++) //turn all the LEDs off
{
strip.setPixelColor(i, strip.Color(0, 0, 0));
}
strip.show();
//Turn on only the LEDs based on distance (the closer to the wall, the
//greater the number of LEDs turned on)
for(i=0; i<val2; i++)
{
strip.setPixelColor(i, c);
}
strip.show();
delay(100);
}
}
Assembly plan The assembly plan for the S1341 breakout board.
R1: 47 kohm (0201)
R2,R3: 1 kohm (0201)
C1: 100 nF ceramic (0201)
Q1: SI2302DS
Q2: BCR112
D1: BAS316
D2: yellow LED (0201)
U1: PIC10F320T-I/OT (MF1341)
Miscellaneous:
- 6-way male pin strip
- 3-way male pin strip
- 2-way male pin strip
- S1341 printed circuit board (16 x 11 mm)
 Wiring diagram of the breakout board, Beetle and LED ring.
We wrap up this article with the build; we start from the breakout board (given the complexity of the assembly we decided to make it available already assembled…) which begins with the preparation of the double-sided printed circuit board, for which the copper-side traces are available for download.
SMD preparation and solderingOnce the board has been etched and drilled, you need to move on to assembly, which requires a minimum of equipment, since the components are surface-mount and the ToF sensor comes in a GAL package with contacts underneath. So get yourself a fine-tip soldering iron, some solder wire no more than 0.5 mm in diameter, some thin flux paste and a small brush to spread it, plus tweezers to handle the components and a magnifying lens to check that they are first positioned and then soldered correctly. Desoldering braid will also come in handy to remove any excess solder, which could short-circuit adjacent pins or pads.
Soldering the VL53L0X requires a hot-air station. Assembly should start with the VL53L0X, tinning and then coating the corresponding pads on the board with flux; then, if you have a heating plate, suspend the PCB at a suitable distance above it, otherwise heat the board from the side opposite the components with air at 260 °C for about ten seconds, then rest the board on a table (not a plastic one…) and, after positioning the chip with tweezers well centred in its holes, heat it with the hot-air jet until you see it “sink” onto the pads. At that point remove the hot air and switch the station off.
Now move on to the resistor and capacitor chips, then place the voltage regulator well centred on its pads (spread with flux paste) and oriented as shown in the assembly plan; carry on with the MOSFETs and finish with the pin strip that provides the connections to the Beetle.
When using the flux, be careful not to dirty the holes on the surface of the VL53L0X, which must stay free and clean, otherwise the distance detection and measurement system will malfunction. Once assembly is complete, use the magnifying lens to check that all the components are in place, well soldered (good solder joints are shiny, while dull ones risk oxidation and intermittent contact…) and centred on their pads; also check that there are no solder whiskers creating short circuits.
Final assemblyOnce the sensor breakout board is built you have to connect it to the Beetle as shown in the wiring diagram and then connect the Beetle to the LED ring; you will power the whole thing by supplying a stabilised 5V only to the + and – pads of the small Arduino, since from there the 5V will then reach both the breakout board and the Neopixel ring.
For the project we made a 3D-printed enclosure in PLA, or rather two enclosures to be joined by a rectangular PVC conduit for electrical installations. In the upper enclosure you will fit the display made up of the Neopixel LED ring and the Arduino Beetle, and in the lower one the breakout board; this latter “body” should be positioned at the typical height of the vehicle’s bumper, so as to detect the distance that matters most to us, namely that from the most protruding part. That done, you are ready to enjoy your assistant.
Related productsThe post Laser Parking Assistant Using ToF Technology appeared first on Open Electronics.
Gartner Forecasts Global AI Spending to Reach $2.7 Trillion in 2026, Up 49.5%
Worldwide spending on AI is forecast to total $2.7 trillion in 2026, a 49.5% increase year-over-year, according to Gartner, Inc., a business and technology insights company.
“Demand for AI infrastructure (including AI-optimized IaaS, AI-optimized servers, AI network fabric, AI processing semiconductors and devices) to support anticipated future workloads remains strong and inelastic to pressures from memory related pricing increases,” said John-David Lovelock, Distinguished VP Analyst at Gartner. “The buildout of AI data center capacity is the largest infrastructure project humanity has even undertaken. The capacity growth from hyperscalers and service providers purchasing AI-optimized servers will continue to be the largest single area of spending.”
In the software market, vendors across different software types are rapidly embedding agentic AI within their existing products to maintain relevance in the market and defend against new cross-functional agents (see Table 1). With GenAI firmly in the Trough of Disillusionment in 2026, enterprises are using these simpler embedded AI features from their incumbent software providers to grow operational efficiency and automate workflows, improve customer engagement and enhance decision making.
Table 1: Worldwide AI Spending by Market, 2025-2027 (Millions of U.S. Dollars)
| Market | 2025 | 2026 | 2027 |
| AI Services | 434,046 | 576,481 | 745,655 |
| AI Cybersecurity | 25,920 | 51,347 | 85,997 |
| AI Software | 288,168 | 461,637 | 656,353 |
| AI Agents and Assistants | 16,481 | 29,219 | 65,472 |
| Generative AI Models | 13,021 | 28,266 | 51,620 |
| AI Platforms for Data Science and Machine Learning | 19,405 | 26,445 | 35,552 |
| AI Application Development Platforms | 6,885 | 9,541 | 12,478 |
| AI Data | 826 | 3,126 | 6,480 |
| AI Infrastructure | 981,920 | 1,484,397 | 1,977,685 |
| Total AI Spending | 1,786,671 | 2,670,460 | 3,637,292 |
“Meanwhile enterprises are turning to service providers less often to help them manage the business transformation, and more often for the smaller indirect projects to exploit AI features of their incumbent software system,” said Lovelock. “The risks associated with vendor lock-in, data sovereignty, and run-away costs are not deterring buyers from adopting these proprietary capabilities. The combination of transformation and indirect projects are forecast to drive a $1.2 trillion opportunity in AI services by 2030.”
Near-Term Outlook ChangesThe short-term outlook for AI application development platforms has increased from 28% growth in 2026 in the previous forecast to 39% in this quarter’s forecast, as enterprises, software providers and services firms seek to develop custom AI applications tailored to their individual needs. Enterprises are looking to their providers to help them manage their costs and embed usage tracking into their workflows to evaluate success. For model providers, the pressure to offer more cost-efficient models that are aligned to enterprise use cases is opening a small but growing opportunity for domain-specific language models (DSLMs). As a result, the 2026 growth rate for generative AI models has increased from 110% growth in the previous forecast to 117% growth in the current forecast.
Long-Term Outlook ChangesIn the current forecast, Gartner has separated cross-functional agents and assistants from AI software and added consumer agents and assistants into the AI spending forecast to better show the emerging opportunity in this area.
The post Gartner Forecasts Global AI Spending to Reach $2.7 Trillion in 2026, Up 49.5% appeared first on ELE Times.
Nuvoton Unveils NAU85L42YG Quad ADC for Multi-Microphone Voice Capture Applications
Nuvoton Technology Corporation has introduced the NAU85L42YG, a high-performance quad-channel audio ADC designed to accelerate the development of wireless streaming and real-time voice-capture products. The device features Nuvoton’s on-chip silicon signal-processing technology, including low-latency decimator (DECM) digital linear and non-linear filters. These low-pass filters are designed to support wireless real-time streaming applications. The NAU85L42YG also supports a wide supply-voltage range and incorporates robust system protection features.
The NAU85L42YG is a high-performance quad-channel audio ADC designed for audio systems that use both analogue and digital microphone inputs, helping simplify system integration and reduce the need for separate circuitry. The device integrates four ADC channels and supports I²S, PCM and TDM digital audio output interfaces. It also features an advanced on-chip signal-processing engine with a fractional FLL that supports various input clocks and automatic clock detection for BCLK and MCLK. In addition, the NAU85L42YG offers a wide supply-voltage range and robust system protection features.
Addressing Industry Pain Points in Multi-Mic DesignWe are pleased to announce significant advancements in the NAU85L42YG, setting a new benchmark for reliable voice capture in 4-array microphone algorithm applications. Designed with precision and adaptability, the NAU85L42YG ensures robust performance by allowing the host SoC to seamlessly detect any microphone malfunction through Mic Diagnostic monitoring. This proactive detection, combined with customer adaptive algorithms, delivers real-time, dependable signal quality. As a result, the NAU85L42YG empowers host-side algorithms to perform at their best, providing exceptional accuracy and reliability in voice capture. These features underscore the NAU85L42YG’s market advantage and reinforce our commitment to innovation and excellence in audio technology.
Conventional quad ADCs without low pass filters will cause delay / high latency during audio data transmission on critical events, especially in real-time stream processing applications. It will cause a mismatch between audio and video streaming, bringing a worse user experience. Nuvoton’s new quad ADC design significantly addresses this challenge by reducing latency time to just one-sixth of what conventional quad ADCs offer. This improvement makes the NAU85L42YG an ideal solution for WiFi or Bluetooth wireless devices that demand low group latency to deliver an outstanding audio user experience.
Key Technical Highlights & Feature Summary YG- 106 dB SNR / DR @ 1 Vrms& 2 Vrms
- Support up to 192 kHz at 24-bit high resolution
- Develop low latency decimator digital linear and non-linear filters for low latency real time processing
- Built-in intelligence of microphone diagnostic & auto clock detection for algorithm quality assurance
- Flexible output interface supporting PCM / I 2 S / TDM formats for seamless connection and easy integration with audio processors
- Two separate low-noise microphone bias suppliers
- Wide temperature range: -40°C ~ +105°C (Industrial grade)
- Compact package of QFN-32 (4 X 4 mm) with low power <12.4 mW/Channel
The post Nuvoton Unveils NAU85L42YG Quad ADC for Multi-Microphone Voice Capture Applications appeared first on ELE Times.
MCUs for power conversion and motor control feature PQC

A new microcontroller family boosts real-time control performance for power and motor applications through higher control-loop frequency, accuracy, and system efficiency. This enables the MCUs to meet the needs of applications that require precise, high-speed control for power conversion, including AI server PSUs, EV charging systems, high-end motor control, solar, and switched-mode power supply (SMPS).
Infineon’s PSOC Control C3 Performance Line is based on Arm Cortex-M33 dual-core architecture operating at up to 200 MHz. These MCUs—featuring a programmable power control accelerator (PPCA) hardware accelerator—offer zero-wait-state access to analog and digital peripherals to enable high-performance systems to respond to real-time events with minimal delay.

Figure 1 The new MCU family mainly targets motor control and power conversion applications. Source: Infineon
The PSOC Control C3 MCUs are also wide-bandgap (WBG)-ready with fast, precise analog processing and digital control to improve control-loop accuracy and system efficiency. They support systems designed with WBG switches while achieving best-in-class control loop frequencies, accuracy, and efficiency for applications such as data centers, telecom, solar, and EV charging systems.
“The family is designed for digital control applications that need higher switching frequencies while providing precision, security, and maximum system efficiency,” said Steve Tateosian, senior VP and GM of IoT, consumer, and industrial MCUs at Infineon Technologies.
“As the industry shifts from analog to digital control for power conversion and motor control applications, the PSOC Control C3 Performance Line meets these needs for increased performance, system flexibility, security, and scalability without increasing the footprint,” he added. Tateosian also noted that the MCUs provide high functional integration for multi-output power supplies and low standby power for battery-powered applications.

Figure 2 The new real-time control MCUs are scalable in terms of features, packages, pinouts, memory, and performance. Source: Infineon
Security is also a key tenant of these control MCUs for power conversion and motor control applications. The MCUs are compliant with post-quantum cryptography (PQC) requirements for firmware protection outlined in the Commercial National Security Algorithm (CNSA) Suite 2.0.
The CNSA 2.0-compatible MCUs include SHA-512 and LMS firmware verification for secure boot and firmware update verification. These MCUs also support Platform Security Architecture (PSA) Level 3 enablement.
These real-time control MCUs are supported by the ModusToolbox Power Suite and Motor Suite GUI. These unified software and ecosystem platforms aid developers with dedicated tools and advanced libraries.
Samples of the PSOC Control C3 Performance Line MCUs with PQC compliance are available now.
Related Content
- Logic Gates With Microcontroller
- MCUs specializing in motor control, power conversion
- Post-quantum cryptography (PQC) knocks on MCU doors
- Unlocking real-time control with digital signal controllers
- The PQC Silicon Is Here Today for Tomorrow’s Quantum Threats
The post MCUs for power conversion and motor control feature PQC appeared first on EDN.
High Boy: The Pocket Tool for Learning Radio and Wi-Fi
High Boy is an open-source pocket tool designed for safely learning about Wi-Fi, RF, NFC, IR, BLE, and GPIO. It is a modern, updated alternative to the Flipper Zero, with more radios, greater processing power, and a color LCD screen. The project comes from High Code and is a natural choice for those who want a Flipper Zero but cannot get one, or for those looking for a similar device with more power under the hood.
The device integrates two ESP32 MCUs for processing power. This dual architecture allows it to handle multiple radios simultaneously without slowdowns. Additionally, the 2-inch color LCD screen provides a clear, readable interface for displaying information and interacting with the device.
Integrated radios and featuresHigh Boy includes radios for Wi-Fi, RF, NFC, IR, and BLE. This variety of protocols makes it a complete tool for exploring the world of wireless communications. For example, you can use it to analyze RF signals, read NFC tags, control IR devices, and experiment with Bluetooth Low Energy.
- Wi-Fi for network analysis and security testing
- RF for short-range radio communications
- NFC for reading and writing tags
- IR for controlling infrared devices
- BLE for experimenting with Bluetooth Low Energy
- GPIO for interacting with external components
Support for GPIO interaction opens up many possibilities. You can connect sensors, actuators, and other modules to create custom projects. Additionally, the Octobit mascot adds a touch of personality to the device, making it more appealing to younger makers.
Price, delivery, and funding campaignHigh Boy is available through a funding campaign. The super early bird price is 179 dollars, a competitive cost for a device with these specifications. Delivery for those who purchase at this stage is expected in February next year. The High Code funding campaign gathers all the details on available versions and shipping timelines.
For those who want to approach this world, there are cheaper alternatives to start with. For example, the ESP32-C6-Zero development kit is a starting point for learning the basics of IoT programming. Additionally, the ESP32 development board with Wi-Fi and Bluetooth offers 32 GPIOs for experimenting with different components.
High Boy represents a step forward compared to similar devices. The dual ESP32 MCU ensures high performance, while the color LCD screen improves the user experience. If you are looking for a tool to learn and experiment safely, this device deserves attention.
Source: https://www.indiegogo.com/en/projects/highboy/high-boy
The post High Boy: The Pocket Tool for Learning Radio and Wi-Fi appeared first on Open Electronics.
КПІшники перемогли на GreenChem Demo Day 2026!

♻️ PolyFuel — проєкт КПІ — посів перше місце серед 11 команд GreenChem Accelerator 2026. Це модульна автоматизована технологія, що перетворює змішані пластикові відходи на компоненти авіаційного та автомобільного бензину, технічний вуглець та дозволяє генерувати додаткову електроенергію.
FLo: the wireless macropad configured over USB
FLo is a wireless macropad that solves a common problem: changing shortcuts without reflashing the firmware. The board, based on the ESP32-C3 Super Mini, sends key sequences over Bluetooth and receives its configuration over USB from a desktop app. You set a shortcut, unplug the cable, and keep using the keyboard wirelessly.
The project, made by shan, uses Bluetooth transport to send keys as an HID keyboard. Macro configuration happens through a serial protocol over USB at 115200 baud. The firmware stores macros in the ESP32’s NVS partition, with keys from m1 to m4 and default values like ‘a’, ‘b’, ‘ctrl+c’, and ‘ctrl+v’. So even after a reboot, the settings stay in place.
The serial protocol and commandsThe serial protocol includes commands like HELLO for identification, SET1-SET4 to write macros, PRINT to display them, and TEST to read pin states and the BLE connection. The desktop app identifies the board via the ‘ESP32-C3-READY’ response to the HELLO command, then sends the new macros over USB. In addition, the firmware uses INPUT_PULLUP on all input pins, with the other side of each switch connected to ground, so a press is read as LOW.
Encoder rotation controls system volume, while pressing the encoder and the three buttons triggers the assigned macros. The GPIO pins used are: GPIO 7, 8, and 9 for the buttons, GPIO 5 and 4 for the encoder, GPIO 2 for the encoder button. Estimated assembly time is 3 hours. shan’s repository collects the code and details to rebuild the project.
What you need to build itTo assemble FLo you need a few components: an ESP32-C3 Super Mini board, three tactile buttons, a rotary encoder with a button, a linear switch, a perf board, and wires. The firmware is written with the Arduino IDE, using the ESP32-BLE-Keyboard library and pyserial for the desktop app. The ESP32-C3 Super Mini handles the radio and USB, and is compact enough to fit in a printed case.
Assembly on a perf board requires attention to the connections, but the project is designed to be replicated in a few hours. The buttons go between GPIO pins and ground, with the internal pull-up resistor enabled by the firmware. The encoder connects to two GPIO pins for rotation and a third for the center button.
- 3 tactile buttons for the main macros
- 1 rotary encoder with push for volume and the fourth macro
- 1 ESP32-C3 Super Mini board with radio and USB
- Perf board and wires for the connections
USB configuration separates programming from everyday use: you don’t need to reflash to change a shortcut. Just plug in the cable, open the desktop app, and send the new value with SET1-SET4. The macropad responds immediately and saves everything in NVS, ready for wireless use.
Source: https://github.com/lil-shan/Flo-Macropad
The post FLo: the wireless macropad configured over USB appeared first on Open Electronics.
Why SiC Is Critical to BMW’s Next-Generation 800V EV Powertrain
Silicon carbide (SiC) power semiconductors are increasingly being adopted in high-voltage electric vehicle (EV) powertrains as manufacturers are achieving higher efficiency, faster charging, and improved power density in next-generation EV powertrain designs. And the most recent practical demonstration related to this comes from Japanese semiconductor company ROHM Semiconductor announced that its SiC MOSFETs are being used in BMW’s sixth-generation electric powertrain, named the Neue Klasse.
The electric powertrain of BMW’s Gen6 is based on an 800V architecture to enable faster charging and more efficient high power energy transfer while supporting higher-power charging and powertrain performance of the next-generation powertrain. BMW has designed an electric motor, a new inverter and other powertrain components optimised for the higher-voltage system. The inverter uses SiC semiconductors to improve power-conversion efficiency and is integrated into electric motor housing.
Greater switching efficiency can also allow engineers to increase power density and reduce the size of supporting components in power-conversion systems. Reducing losses during power conversion lowers heat generation, which can ease thermal- management requirements and contribute to improved overall powertrain efficiency.
The use of ROHM’s SiC MOSFETs in BMW’s Gen6 powertrain highlights the growing use of wide-bandgap semiconductors in future EV power electronics because of its switching performance, voltage capability and power-conversion efficiency. As manufacturers adopt higher-voltage platforms, SiC devices are likely to be critical technology for enhancing power-conversion efficiency, thermal management and charging capacity.
The post Why SiC Is Critical to BMW’s Next-Generation 800V EV Powertrain appeared first on ELE Times.
L&T Semiconductor Technologies Unveils 1200V SiC Platform for EV Power Electronics
L&T Semiconductor Technologies (LTSCT), has announced its first Silicon Carbide (SiC) product platform at SEMICON India 2026. The company has showcased 40 products designed for EV fast charging, traction inverters, microgrids and solid-state transformers. Among the showcased products, a key highlight was the 1200V SiC MOSFET platform for power-conversion applications.
SiC is increasingly adopted in EV power electronics, because it can switch power electronics at higher temperatures and switching frequencies than comparable silicon power devices, particularly silicon IGBTs. In an EV traction inverter, the power semiconductor switches battery DC power into AC power sent to the motor. Increasing the switching and conduction efficiencies of the power devices can increase the overall conversion efficiency.
Higher switching frequencies can also enable engineers to select smaller passive components which can lower the inverter’s size and weight. Additionally, SiC’s high-temperature operation capability contributes to greater thermal management flexibility due to its material and device characteristics. These advantages are relevant to the high-voltage EV architectures such as 800V systems.
By decreasing energy lost as heat during power conversion, higher inverter efficiencies can increase the driving range per charge depending on the overall vehicle design and operating conditions. The difference in range is ultimately limited by the efficiency of the entire powertrain—including batteries, motors, and thermal-management systems—as well as by overall driving conditions.
LTSCT’s SiC platform represents a significant step in the evolution of India’s expanding power-semiconductor ecosystem, especially as EV manufacturers move towards higher-voltage architectures and faster charging. Alongside the SiC platform, the company has showcased a highly integrated BLDC motor controller that is fully designed in India, further expanding its range from individual semiconductor devices to complete power-electronics solutions.
The post L&T Semiconductor Technologies Unveils 1200V SiC Platform for EV Power Electronics appeared first on ELE Times.
SFP: The single-mode module autopsy

This initial entry in a planned dissection series analyzes the insides of a long distance-capable fiber optic cable networking adapter containing a focused-beam laser.
Last week’s tutorial, the conceptual kickoff to the teardown coverage cadence that begins today, provided what I hoped was a concise but comprehensive tutorial into the diversity of implementation options available with small form-factor pluggable (SFP) modules. Today’s premier patient, as mentioned last week, is a 10 Gbit LX SFP+ module. Specifically, it’s TP-Link’s TL-SM311LS, a member of the company’s business-tailored Omada product line.

Two things particularly interest me in perusing the TL-SM311LS product page. First off, the company refers to it there not as a SFP module but as a “Mini GBIC Module”, using the less common alternative naming convention that I’d noted upfront in last week’s coverage.
Secondly, it’s an “LX” module, with the “L” referencing long range transmission capabilities, specifically in this case specified as up to 20 km (~12.5 miles). The “X” typically references a module that’s usable with both single-mode and multimode cable, albeit at differing max transmission distances and, in both mode cable cases, at a common 1310 nm wavelength. However, TP-Link only documents the SM311LS as usable with 9/125 μm single-mode fiber cable, a seeming characteristic of the alternative “LR” module designator.
I sourced the SM311LS from the Resale (formerly Warehouse) section of Amazon’s website, where it set me back $16.99, versus a $19.99 MSRP. Here’s how it arrived, within a generic cardboard shipping box, and as usual accompanied in the following photos by a 0.75′′/19.1 mm diameter U.S. penny for size comparison purposes.


And here’s our patient, with dimensions of 2.1×0.5×0.5 (55.4×13.7×12.9 mm), after freeing it from its Styrofoam and antistatic bag sarcophagus. Top.

Right side (with “right” referencing its orientation when inserted in a network switch or other gear’s SFP port).

Bottom.

And left side.

The double-sided 20-contact (10 per side) connector is on one end.

The other end begs for a bit more explanation.

Removing the dust cap exposes to view the fiber optic connector mate sites, from two perspectives: first right-side-up and then upside down.


How do you tell which is the transmit one, and which is for data reception? One way is to look at the directions of the two arrows at far left in the earlier top side shot. And what’s with the blue-color lever beyond them? For that, we’ll need to revisit the earlier bottom side shot.
Tab-restrained removal, and internal accessSee that tiny tab sticking out of the bottom, to the left of the product label? It’s spring-loaded, temporarily retracting flush with the bottom edge during module insertion and returning to its original position once the module is in place (thereby also locking the module in place). The other means of retracting it, thus enabling module removal, is to move the lever midway through its arc, halfway between the two positions shown in the dust-cap-installed and -removed photos.
And speaking of tabs, did you already notice the tiny ones halfway down both sides in the earlier shots? They’re our pathway inside. Use a small-but-solid “poker” of some sort to pull them back out, and you can then slide the outer chassis away from the interior assembly.


Turning the PCB right-side up again caused the black plastic piece normally covering the fiber optic cable female connectors (and visible in the previous photos) to fall away.

Here’s the underside of the PCB again, standalone and with that plastic piece temporarily back in place.

Now with all supplemental pieces removed, revealing the details of their bottom-pin retraction function operation.


The right side again, this time absent the outer enclosure and other extra bits.

And the left side, upside-down compared to its normal-operation orientation.

One more screw to go.

And the PCB is finally free.

I’ll start with the simple stuff: the SFP and fiber optics connector ends.


Let’s next revisit the PCB underside, now free of its metal surroundings.

The orange-color assemblage at far left is the fiber optic receiver. Below it is the chrome-color laser transmitter. And the ICs to their right? The larger eight-lead one, in a TSOP-1 package, is the GT24C08A-2ZLI, an 8K-bit serial I²C EEPROM from Chinese supplier Giantec Semiconductor. Third-party SFP modules typically use memory such as this to, among other things, “spoof” networking equipment that would normally accept only same-name-brand (translation: expensive) SFP modules.
Remember my last-week comments about how single-mode technology has dramatically dropped in price in recent years, thanks in no small part to the “availability of non-proprietary, widely compatible modules”? Here’s a case study example. And the smaller six-lead IC below and to its right? If I’m right and the PCB mark next to it is “Q1”, then it’s likely a dual-transistor device.
But the “371H” mark on top, which I’m guessing is a date code or lot trace code versus an actual product code, isn’t helpful from an identity-sleuthing standpoint, at least to me. Reader assistance here is as-always appreciated.
I’d wondered, after first seeing all these ICs (and particularly before realizing that the larger one was “only” a nonvolatile memory), why they were on the PCB underside, as I’d assumed they were heat sources. Then I saw the PCB topside for the first time and instantly realized why.

The far more sizeable, albeit sole, device on this side, packaged in a 28-lead QFN and marked “3320C” on the top line, is the Uxfastic UX3320, a G/EPON ONU fiber transceiver developed by another Chinese manufacturer, Xiamen UX High-Speed IC. Presumably, given the lack of other logic anywhere on the PCB, it has integrated SFP interface capabilities.
To that point, and in closing, keep in mind that what we’re looking at today is a conventional (and legacy?) 1 Gbps SFP module. Recall from the “laundry list” in last week’s post that I also have a number of both higher-bitrate SFP and SFP+ modules in my teardown queue, and even a QSFP+ version, along with multimode modules to contrast against this and other single-mode offerings. I don’t know about you, but I’m intrigued to learn not only about each of them in an absolute sense but also relatively speaking, in comparing (including contrasting) them against each other.
With that “teaser” now out there, I’ll close for today. Please let me know your thoughts in the comments!
—Brian Dipert is the associate editor, as well as a contributing editor, at EDN.
Related Content
- SFP: Add-in module delivers diminutive performance, flexibility
- TP-Link MC220L: Media conversion keeps the network well
- The whole-house LAN: Achilles-heel alternatives, tradeoffs, and plans
- Design considerations in high-speed fiber networks
The post SFP: The single-mode module autopsy appeared first on EDN.
Hyundai 120 kW DC Fast Charging in Delhi: Enhances EV Charging Time and Thermal Management
Hyundai Motor India has inaugurated 120 kW DC fast-charging stations at strategic locations in New Delhi. These high-power charging stations are intended to provide faster charging for EV users and can be accessed through the myHyundai app and other charging-management applications. The company’s DC fast-charging solutions in India currently range from 60 kW to 240 kW, offering different charging power levels based on the vehicle’s configuration.
A 120-kW DC fast charger provides significantly higher charging power compared to conventional AC charging systems and can therefore reduce charging time. The actual charging time for an EV battery depends on several factors, including the vehicle’s maximum DC charging capability, battery capacity, state of charge, temperature, and charging curve. The maximum capacity of these inaugurated charging stations is 120 kW, but the EV will only draw power suitable for its charging.
Impact on Grid DemandCharging a vehicle at higher power also increases instantaneous electricity demand. A 120-kW charger operating at its rated output can deliver up to approximately 120 kW of DC power to an EV, excluding conversion and other system losses. Multiple chargers operating simultaneously at charging stations can creates significant local electricity demand of power supply, requiring suitable transformers, switchgear, cables and grid connections.
Thermal Management ChallengesA high amount of heat generates while charging an Electric Vehicle using high-power DC charging. This heat generates inside the battery, cables and connectors. Effective thermal management is therefore required to maintain charging performance and protect components from the extensive heat generated. This can involve liquid-cooled cables, cooling systems, temperature monitoring, and a power-control strategy.
The inauguration of 120 kW charging station represents growing shifts towards faster charging consumer infrastructure in India. The speed of charging an EV will ultimately depend on battery technology, interaction between charger power, vehicle architecture, thermal management and available grid capacity.
The post Hyundai 120 kW DC Fast Charging in Delhi: Enhances EV Charging Time and Thermal Management appeared first on ELE Times.
Australia Operationalises LRASM and JASSM- ER Strike Missiles
RAAF has declared initial operational capabilities for the AGM-158C LRASM and AGM-158B JASSM-ER. The AGM-158C LRASM will vastly increase the strike range of Australia against both land and maritime targets in defended environments. LRASM is an air-launched, self-propelled, autonomous anti-ship missile with autonomous target identification capabilities. It is designed to detect and destroy large surface targets at ranges greater than 370 km. It uses sensor and internal processing to find, identify, and attack targets in GPS- and communications-denied environments, and its low-observable features and flying attitude provide a higher probability of survivability against today’s ship-based radars.
JASSM-ER is a long-range stealth cruise missile for land attack missions. The range is listed as “about 900 km (560 mi)” by the RAAF. (The missile allows the launching aircraft to remain outside the range of enemy air defences). Both weapons are being added to the RAAF F/A-18F Super Hornet force, which is firing the weapons in areas such as weapons storage, mission planning, aircraft loading, and targeting. Australia has already employed two LRASM and two JASSM-ER missiles from the Woomera Test Range in Australia and two LRASM from P-8A Poseidon aircraft in RIMPAC 2026, attacking the target.
The two systems also show how modern missile systems leverage advanced precision navigation, sensor-fusion, autonomous processing, and electronic-warfare resistance. Their strategic use also underscores how Australia is turning to long-range deterrence and maritime security in the Indo-Pacific, with aircraft carrying out strikes well outside the range of increasingly capable air-defence systems.
The post Australia Operationalises LRASM and JASSM- ER Strike Missiles appeared first on ELE Times.
Ukraine Tests New Interceptor Against Shahed-Type Attack Drones
Ukraine is experimenting with its own technology capable of intercepting unmanned aerial threats, as the country looks for inexpensive ways to fight back against swarms of attack drones. The Ukrainian president Volodymyr Zelenskyy has claimed that the country has tested out its own system that was able to shoot down a Shahed-type drone, although there is still more work to do to make the technology more reliable. Shahed-family one-way attack drones have been used to devastating effect against cities, energy plants and other infrastructure, and their relatively low price can create an economic deterrent for traditional air defences that destroy the inexpensive drone and thereby deplete an expensive missile.
As yet, no specifics about Ukraine’s new system have been made public, but contemporary drone-interception weapons have all the components listed above. A radar, radio-frequency sensor, acoustic array and electro-optical cameras could detect and classify a target; AI software could identify an enemy drone from a flock of birds or formations of friendly fighters; and a guidance system could send an interceptor from a stand-off position toward the threat. Cheaper interceptor drones are also being designed to work between electronically armed missile defences and advanced sensors, using autonomous navigation, operator-assisted targeting, and onboard vision processing to find a target on approach.
Nonetheless, consistent functioning is another matter. An interceptor must work at night, in bad weather, and be able to fight off electronic jamming and adapt to the evolving tactics of attacking drones. The missile launchers Ukraine has reportedly tested are part of a broader evolution in air defence. In future, air defence will probably consist of a patchwork of guns, missiles, electronic warfare, directed energy, and reusable or disposable interceptors.
The post Ukraine Tests New Interceptor Against Shahed-Type Attack Drones appeared first on ELE Times.
Defender Unveils Three Wolf Series II Military Vehicle Variants
Defender has introduced three variations in its range of military mobility at DVD 2026, the British Army’s leading defence and security exhibition. The new Tactical Mobility Vehicle, Mono-Tactical Mobility Vehicle and Utility Vehicle have been created as the initial variants in a family of military vehicles that is being built through JLR’s Defender Defence Division.
Based on Defender’s dedicated D7x platform architecture, Wolf Series II adopts monocoque construction, negating the need for a traditional body-on-frame setup. JLR claims the approach delivers a more rigid platform, enables higher payloads, and provides a base for adaptation to specific military uses. The architecture is said to deliver a torsional rigidity of 29kNm per degree.
The three variants have been specified according to the UK Ministry of Defence Light Mobility Vehicle tender specifications. Defender expects to be able to supply the platform to NATO defence agencies. In addition to the three variants, other possible configurations include a general-purpose platform, command-and-control vehicle and battlefield ambulance. JLR says the Defender platform has undergone over 62,000 engineering sign-off tests, traversed deserts, snow and ice caps, high altitude environments and extreme off-road conditions.
In addition to military radios, sensors, electronic countermeasures, command and external power systems, the platform could also carry other items depending upon what the customer may want. For readers in India, the programme is more important as JLR is owned by Tata Motors Passenger Vehicles. Wolf Series II shows how a commercially derived platform can be emplaced, electronically configured, and manufactured for today’s needs of tactical operations.
The post Defender Unveils Three Wolf Series II Military Vehicle Variants appeared first on ELE Times.
GM Defence Accelerates PAC-3 MSE Missile Component Production
GM Defence has produced its first lots of missile housing assemblies for Lockheed Martin’s Patriot Advanced Capability-3 (PAC 3) Missile Segment Enhancement (MSE) interceptor, showcasing how its automotive production expertise can accelerate defence manufacturing scale-up. It is understood that the first lots of components were produced just 22 days after the firm signed its manufacturing agreement on 6 August 2026. Items that normally take months to produce were provided to Lockheed Martin on 28 August.
The PAC-3 MSE is the most sophisticated interceptor in the Patriot air-and-missile-defence system. Whereas many missile systems primarily utilize explosive fragmentation for neutralization, PAC-3 MSE utilizes “hit-to-kill” technology by destroying ballistic missiles, cruise missiles and other threats in flight through direct impact. PAC-3 MSE’s operation depends on precise navigation, high-performance control electronics, a strong missile-rocket motor, and nearly real-time communication with the patriot system.
This partnership enables GM Defence to leverage automotive expertise in high-volume production, quality systems, industrial automation and supply-chain management. Lockheed Martin is investing heavily in the production of the PAC-3 MSE, Terminal High Altitude Area Defence System, and other precision-guided missile systems as the global demand for missile-defence systems continues to grow.
The fact that this is happening is in itself important, since many defence companies have long product lead times and often rely on a handful of specialised suppliers. Engaging a major automotive manufacturer in the supply chain might increase production and supply-chain diversity. The undertaking illustrates the value of taking commercial manufacturing of sophisticated military systems more rapidly while maintaining the precise quality needed for missile parts.
The post GM Defence Accelerates PAC-3 MSE Missile Component Production appeared first on ELE Times.
Lockheed Martin Unveils AIM-260 JATM for Next-Generation Air Combat
US Air Force has released cutting-edge missile against China. Lockheed Martin has launched the AIM-260 Joint Advanced Tactical Missile (JATM). It’s a new air-to-air missile that helps US fighter jets shoot down ever more technologically advanced rivals in contested airspace. The program has remained very secretive throughout its development, and much remains unknown about the missile.
The AIM-260 is an upgrade for the AIM-120 Advanced Medium Range Air-To-Air Missile (AMRAAM). It will probably have a longer range than the AIM-120, with the ability to target “extremely low observability, highly agile threats.” The missile system is being prepared for integration with future US combat aircraft, including the F-22 Raptor and F-35 Lightning II. The system is expected to be fitted with advanced electronic guidance systems, a data link, and anti-jamming features. This would give the missile the ability to receive updated targeting data after launch and to function in a jamming environment.
Lockheed has also agreed with the US Department of Defence to ramp up production to increase capacity, bolster the missile supply chain and facilitate multi-layer buying. Australia has also progressed with a plan to buy JATM as part of a proposed weapons package. The AIM-260 is an evolution of how air warfare is conducted, where fighters fight at increasingly great distances without giving away their position. The missile’s development also showcases how important small hardware processors, radar-seeker technology, resilient data links, and electronic-warfare resistance are in new missiles.
The post Lockheed Martin Unveils AIM-260 JATM for Next-Generation Air Combat appeared first on ELE Times.
Custom Bluetooth Audio PCB
 | Hey folks! As I wasn’t satisfied with the current Beyerdynamic Bluetooth offerings I decided to make another Bluetooth mod. This is a little different as it’s “Plug and Play“, looks quite professional and works as good as any other BT headset. I made a custom PCB and some 3D printed parts to make mods easy! Check out the GitHub repository: https://github.com/farbefreak/DT770-BT-Mod for more details. [link] [comments] |
ESSCI, NIELIT Sign MoU to Boost Semiconductor, AI, IoT and Drone Skilling
In a move aimed at creating a job-ready talent pool for India’s fast-growing electronics and emerging technology sectors, the Electronics Sector Skills Council of India (ESSCI) and the National Institute of Electronics & Information Technology (NIELIT) have signed a Memorandum of Understanding (MoU) to expand industry-aligned skilling in semiconductors and new-age technologies. The partnership will focus on developing and delivering training and certification programmes in areas including the following:
- Semiconductors
- Artificial Intelligence (AI)
- Internet of Things (IoT)
- Drones
- Embedded systems
- Industry 4.0
- Cybersecurity
- Electric vehicle electronics
As a Central Council with industry interfaces, ESSCI aims to strengthen the link between industry demand and the skills being imparted to students, professionals and young jobseekers through this collab. The Council will contribute industry-relevant Standards & Qualifications while supporting alignment with the National Skills Qualification Framework and Skill India requirements.
ESSCI & NIELIT MoU: A Futuristic Skill-development InitiativeSemiconductor and emerging technology skilling will be a major focus. Under the partnership, NIELIT’s virtual laboratories will be leveraged for fresher skilling and upskilling in semiconductors and new-age areas such as AI, IoT and drone technology. The two organisations intend to work towards development of advanced laboratories, Centres of Excellence and industry-oriented training facilities.
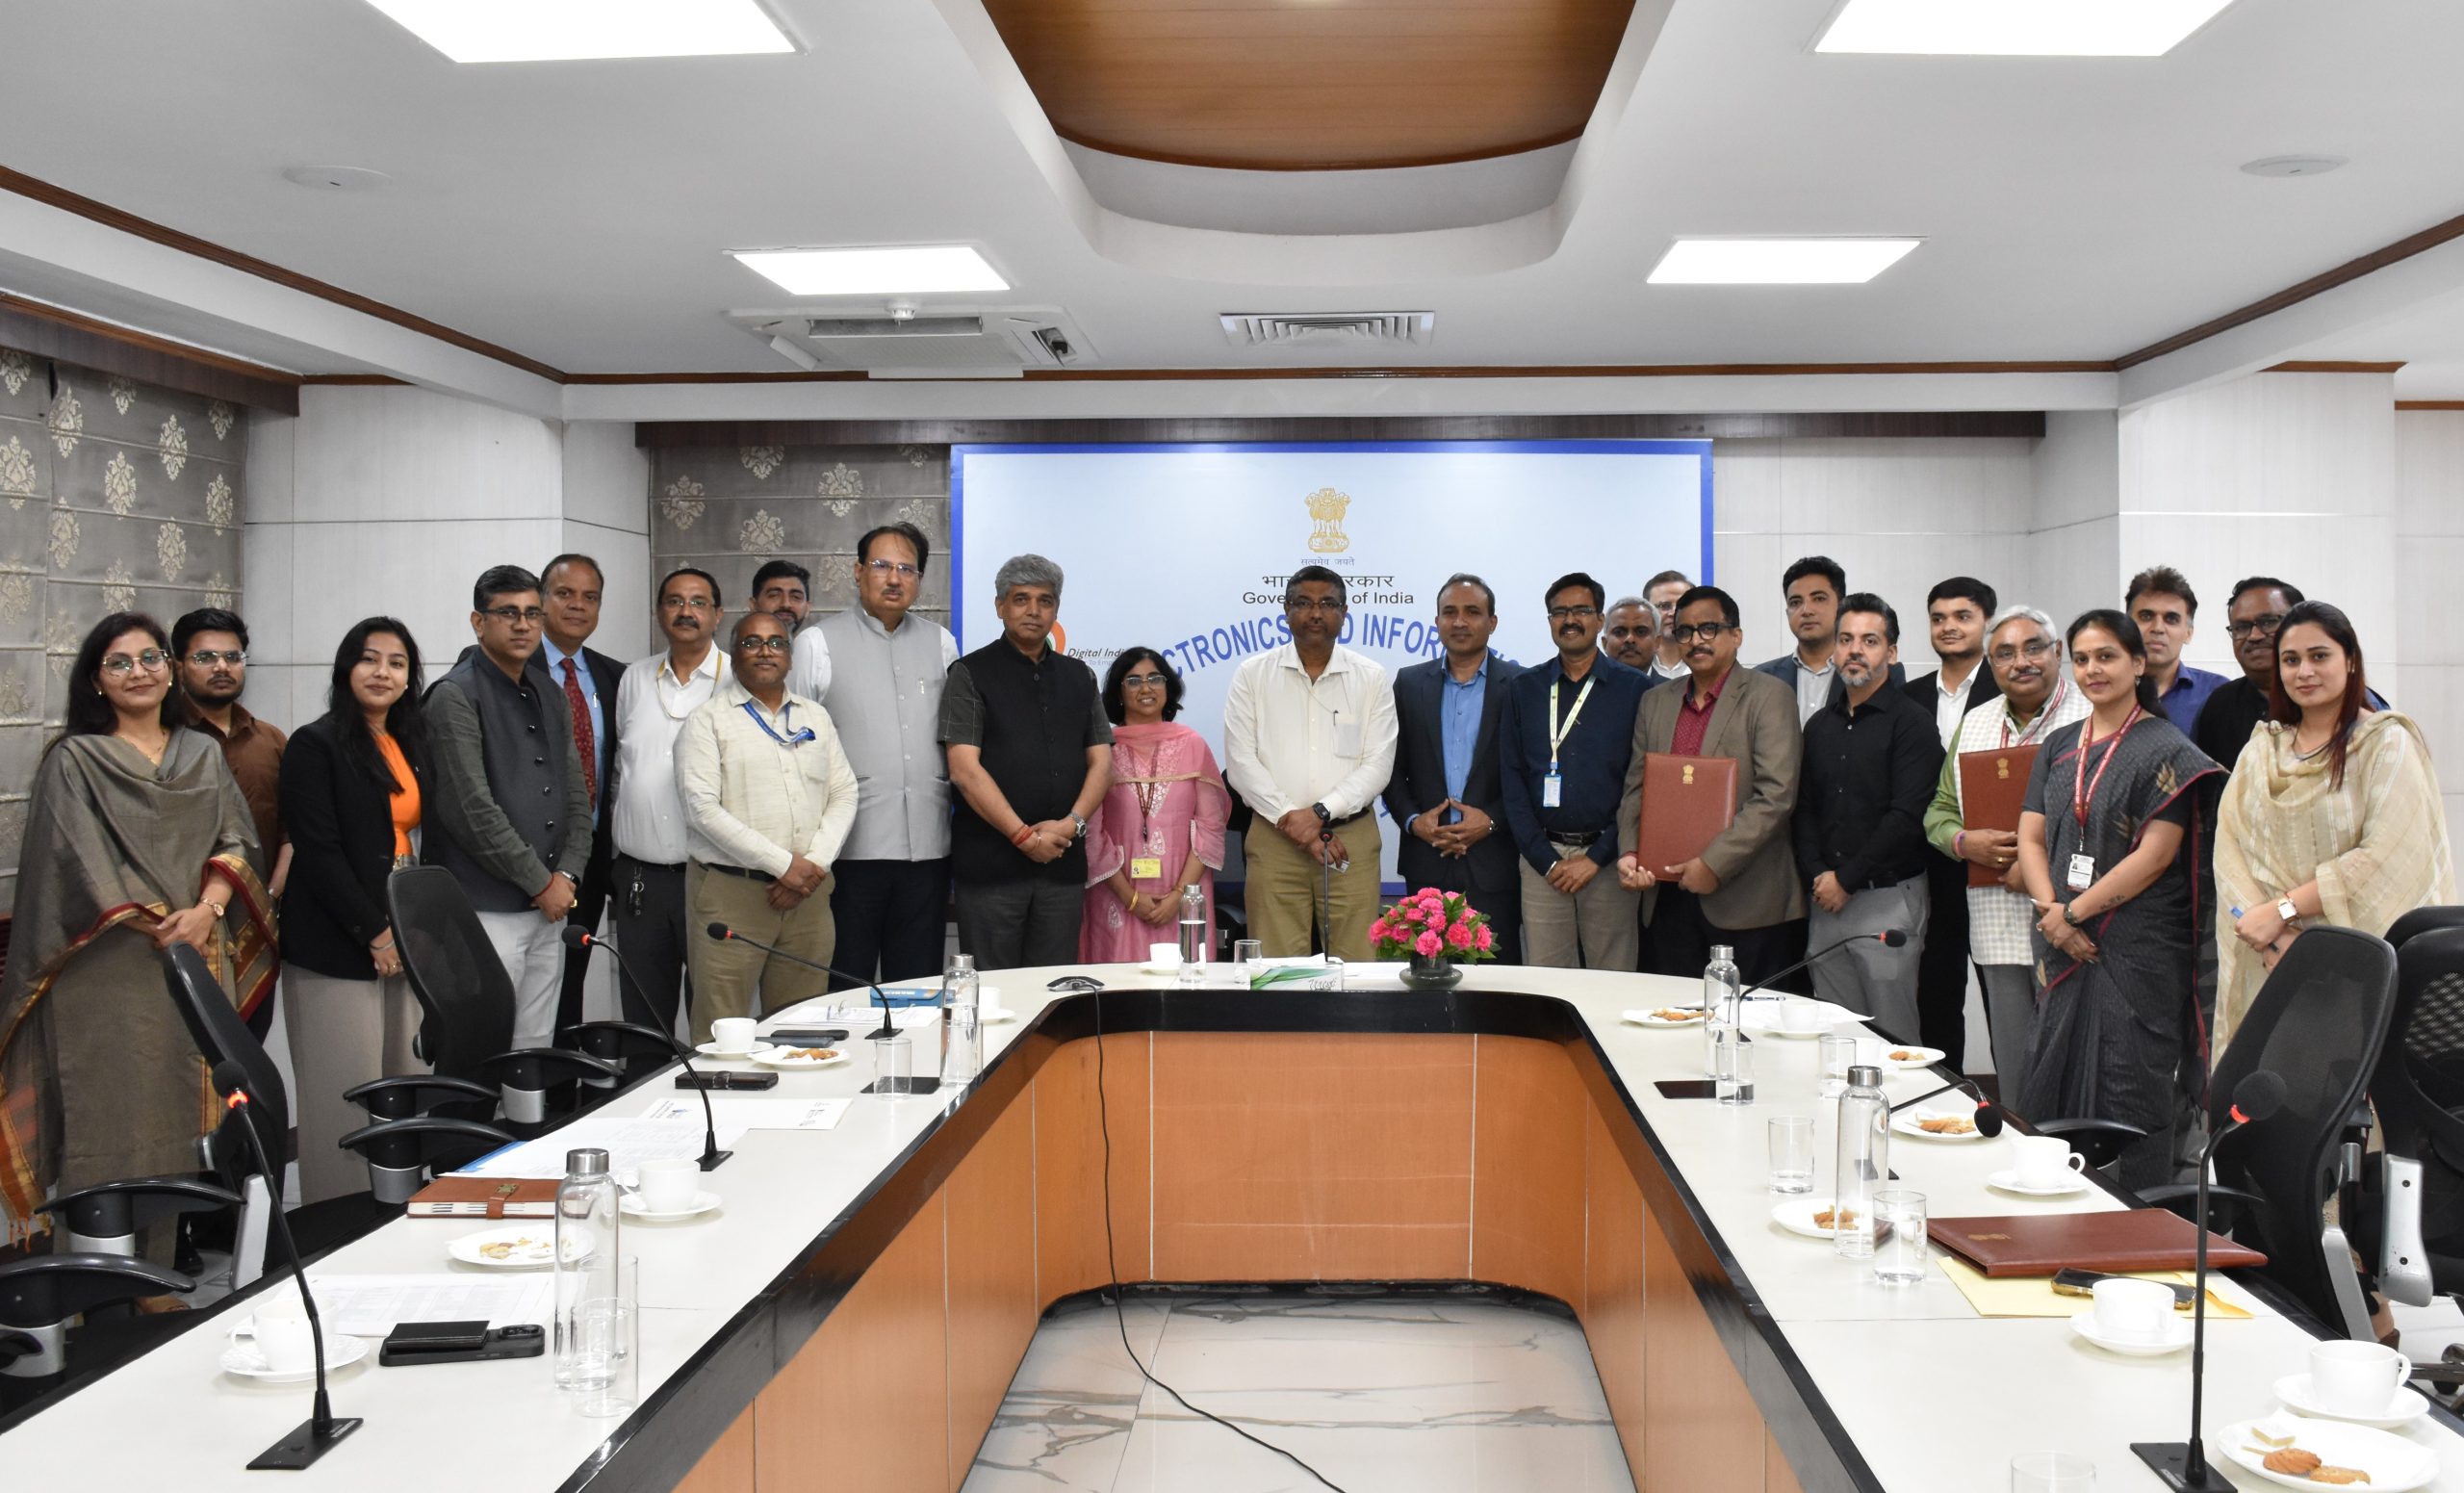
The two organisations will jointly develop new courses, certifications and competency frameworks, besides conducting Training of Trainers, Training of Assessors, faculty development programmes, workshops and awareness initiatives. The partnership will further support joint research, workforce studies, knowledge sharing and industry-academia collaboration to identify emerging skill requirements.
Commenting on the development, Madhvendra Singh, CEO, ESSCI, said, “India’s ambitions in electronics and semiconductors require a strong pipeline of skilled professionals who are ready for rapidly changing technologies. This partnership with NIELIT will help us take industry-led skilling deeper, while creating stronger opportunities for learners to gain relevant skills and industry exposure.”
The MoU will also facilitate apprenticeships, internships, industrial visits, placements and other industry engagement opportunities. ESSCI will leverage its industry ecosystem to support participation from companies and other stakeholders in collaborative skill development initiatives.
The post ESSCI, NIELIT Sign MoU to Boost Semiconductor, AI, IoT and Drone Skilling appeared first on ELE Times.
Pages