

Збирач потоків
ASMPT Expands Factory Equipment Centre Software to Manage SMT Placement Head Maintenance
ASMPT SMT Solutions has expanded its Factory Equipment Centre software to include placement heads in its equipment maintenance system, alongside feeders and nozzles. The software helps manufacturers track the condition and location of movable SIPLACE equipment used in electronics production.
It also allows manufacturers to schedule maintenance based on actual equipment usage and ensures that inspected components are properly returned to the production floor. These features aim to reduce equipment downtime, improve production reliability and increase the overall productivity of surface-mount technology (SMT) lines.
Feeders, nozzles and placement heads frequently move between machines, setup areas, warehouses and maintenance departments. Manufacturers need to track the location, condition and availability of each component to avoid disruptions in production.
ASMPT’s Factory Equipment Centre software helps manage these assets across the factory. It collects data from machines, tracks individual components, monitors their usage, schedules maintenance and records their current status. Components that require repair or servicing are removed from production and returned to the shop floor only after successfully passing functional tests.
According to Eric Kirschner, Senior Product Manager at ASMPT SMT Solutions, the system follows the same approach for feeders, nozzles and placement heads: manufacturers can track the condition of each component and ensure it is working properly before putting it back into production.
Less downtime for placement head maintenanceThe improvement potential of this approach is particularly great when it comes to placement head maintenance. Traditionally, several heads are taken off the line and maintained on site. Depending on the number of machines and heads, this can lead to long downtimes and require additional staff resources. With Factory Equipment Centre, on the other hand, maintenance can be performed one head at a time. If scheduled or usage-based maintenance is due because a certain number of components has been placed or the head exhibits abnormalities, it is replaced and maintained offline. Next, the head’s functionality can be checked at the SIPLACE Head Care Station. The status is entered in Factory Equipment Centre, and the head is returned to inventory. That way, an inspected and documented head is available the next time a head change is needed. With regularly scheduled maintenance, heads can be serviced in a staggered manner to reduce downtimes along the line.
One cycle for all movable assetsThe system works similarly for feeders. After collecting the initial asset data, Factory Equipment Center continuously monitors the counters of all feeders in use on the shop floor. The application knows their location, their usage, and their respective maintenance status. Overdue feeders can be blocked and moved to maintenance, from which they will be released back into production operations only after their functionality has been checked with the SIPLACE X-Feeder Verification System.
In closed-loop nozzle management, so-called “smart nozzles” (each of which is equipped with its own RFID tag), are tracked via their individual IDs. To do this, Factory Equipment Centre continuously receives usage and inspection data from the placement machines. Contaminated or damaged nozzles and those requiring maintenance are blocked, cleaned and inspected – or replaced, if necessary. After successful testing, the system updates their status and releases them back to production operations.
“Whether we are talking about feeders, nozzles or placement heads – ensuring a closed cycle is crucial for us. That’s why we keep track of assets even when they are away from the line and make sure that only tested equipment is allowed to go back to production operations. This improves reliability and reduces avoidable interruptions,” says Eric Kirschner.
The post ASMPT Expands Factory Equipment Centre Software to Manage SMT Placement Head Maintenance appeared first on ELE Times.
Rohde & Schwarz Unveils Five-Channel HMP5050 DC Power Supply With 560 W Output
Rohde & Schwarz is expanding its HMP power supply series with the new R&S HMP5050 model. The company will showcase the power supply at electronica 2026 in Munich ahead of its planned market launch.
Rohde & Schwarz has introduced a new model in its R&S HMP power supply series at electronica 2026 in Munich. The new power supply, scheduled to be available in spring 2027, offers five output channels with a compact design and higher power capacity. It delivers up to 180 W per channel, with a maximum combined output of 560 W. Each channel can be configured to provide up to 15 A of current and 35 V of voltage. The instrument also features low residual ripple of less than 350 microvolts RMS, helping provide a more stable power supply for electronic testing applications.
Users can connect multiple channels in series to achieve higher output voltages or in parallel to increase the available current. They can also connect several R&S HMP5050 units to increase total power or operate up to 64 channels through a central control system. The connected units automatically synchronise, allowing users to control and monitor each channel separately. These features make the R&S HMP5050 suitable for automated testing in manufacturing and other applications that require a precise power supply with multiple output channels.
From November 10 to 13, 2026, visitors to electronica can discover the advantages of the new power supply at Booth A4.307. Rohde & Schwarz experts will use a demo setup to show how this power supply can supply multiple components and circuits at the same time and how channels can be interconnected.
The R&S HMP5050 power supply will officially launch in spring 2027 and will then be available from Rohde & Schwarz and selected distribution partners alongside the existing instruments in the series, the R&S HMP2000 and R&S HMP4000.
The post Rohde & Schwarz Unveils Five-Channel HMP5050 DC Power Supply With 560 W Output appeared first on ELE Times.
Hardware-in-the-loop for Claude: AI builds the PCB, firmware, picks the sensors, SoCs; designs the CAD, and then iterates the designs against a virtual twin (Isaac Sim / Unreal)
 | submitted by /u/Kemerd [link] [comments] |
Bosch to form dedicated semiconductor division, targeting growth in new markets
Electronics at the Computer History Museum (Mountain View) 2014
 | During another trip to HQ in San Jose. Lots of computers and lots of electronics too. [link] [comments] |
"History San Jose" Wireless Exhibition 2015
 | A great history park. I visited during a trip to company HQ in San Jose [link] [comments] |
SemiQ previewing Gen4 1700V, 830A SiC MOSFET modules at electronica
Elethron to build UK AlN substrate manufacturing capability
LakeShark: the pocket-sized portable SDR scanner
LakeShark is a portable SDR scanner and radio workbench that fits in one hand. It was built by SAMS0N1TE around the LilyGO T-Display P4, a board with a 4.1-inch AMOLED display at 568 x 1232, 16 MB of flash and an integrated SX1262 LoRa radio. On top of that there is GPS and a nine-axis motion sensor. So the device receives, decodes and displays everything on its own, with no PC attached.
The heart of the system is the LilyGO T-Display P4, with its ESP32-P4. It is controlled by touch alone, or by adding the detachable keyboard with the MIX-RF radios. Connecting an RTL-SDR Blog V3 or V4 opens up P25 Phase 1 trunking, FM, POCSAG, ADS-B and sub-GHz captures. The onboard SX1262, meanwhile, handles MeshCore or LoRa Labs.
What LakeShark receives with an RTL-SDR attachedP25 Phase 1 trunking is the most demanding part. To decode it LakeShark uses OP25 with Pavel Yazev’s imbe_vocoder, together with DSD, dsd-fme and mbelib. ADS-B receives aircraft at 1090 MHz, with libmodes, dump1090 and ADS-B Scope for the display side. Then there are FM, POCSAG and sub-GHz captures, handled by the librtlsdr and rtl-sdr libraries from Osmocom and by xtrsdr from XTR1984.
- P25 Phase 1 trunking with OP25 and imbe_vocoder
- FM and POCSAG with librtlsdr and xtrsdr
- ADS-B at 1090 MHz with libmodes and dump1090
- Sub-GHz captures from the connected receiver
- MeshCore or LoRa Labs on the onboard SX1262 radio
The optional MIX-RF keyboard adds CC1101, nRF24 and NFC tools. So anyone who wants to experiment on 433 MHz or 2.4 GHz finds the module ready to go, without soldering anything. The HackRF’s USB IQ transport is tested at 2 MSPS, a figure that says how well the system handles the incoming sample stream.
Firmware, offline maps and headless versionsThe LakeShark firmware is released under the GPL-3.0 licence and requires ESP-IDF 5.4.3. The current version for the P4 is 2.3.2. The interface relies on LVGL and the DejaVu fonts, while the offline maps come from CartoTUI, ZeroMesh, libcarto and a PMTiles reader. That way the GPS makes sense even without a network, and the device shows its position on a map already stored in memory.
Not everyone needs the screen. The headless Waveshare ESP32-P4-NANO and ESP32-P4-WIFI6 versions run the same receivers without a display, driven from a serial console or from the Flipper over Bluetooth or the GPIO header. The image for the Waveshare Touch-LCD-4.3 is 480 x 800, while the Touch-LCD-4B and the Smart 86 Box are compiled from source at 720 x 720. In every case the software base stays the same, with ESP-Hosted handling the radio side of the ESP32-C6 module.
Anyone who wants to rebuild the project starts here: the LilyGO T-Display P4, an RTL-SDR Blog V3 or V4, and the MIX-RF keyboard if CC1101, nRF24 and NFC are needed. The code and build instructions are in the SAMS0N1TE repository on GitHub, where the sources and the files for the different hardware versions can be found.
Source: https://github.com/SAMS0N1TE/LakeShark
The post LakeShark: the pocket-sized portable SDR scanner appeared first on Open Electronics.
Як стежити за споживанням енергоресурсів у кампусі у реальному часі
КПІ ім. Ігоря Сікорського продовжує впроваджувати сучасні технології сталого розвитку та прозорості. Відтепер кожен студент, викладач та співробітник університету може стежити за споживанням енергоресурсів у реальному часі завдяки спеціальним аналітичним інструментам.
A wide-range, linearly-programmable DC/DC converter

This Design Idea presents a simple, low-cost, highly flexible, and scalable DC/DC converter.
- The output is linearly programmed by an external, ground-referenced voltage.
- The design is a two-phase flyback converter powered by an input of 15 V to 30 V.
- It provides an output voltage ranging from 0 V to 200 V with a maximum power output of up to 60 W.
- The system is built around a MIC3808/MIC3809 or a similar push-pull PWM controller.
Wow the engineering world with your unique design: Design Ideas Submission Guide
The ChallengeSome applications demand significant DC power delivered at a precisely controlled voltage that may vary over a wide range. Traditional solutions for this requirement often involve:
- Linear regulators: Suffer from low efficiency and high power dissipation.
- PWM step-down converters: Can only generate voltages lower than the rail voltage and lack a voltage feedback loop unless explicitly implemented.
- Digital potentiometers / multiplying DACs: An alternative is substituting the resistive feedback dividers of power control ICs with digital potentiometers. However, this requires digital rather than analog control. It also causes massive changes in the voltage feedback loop gain over the adjustment range, which can destabilize the output voltage.
This simple, generic solution converts power control ICs with a voltage feedback input to allow for wide-range, linearly adjustable DC/DC conversion.
In the preferred implementation, a small-value, voltage-controlled current source is used to remove current from the sensing point of the DC/DC controlling loop’s voltage feedback divider.
- This proposed current source is built using a small MOSFET (such as a 2N7002) and an operational amplifier.
- It is often preferable to use op-amps with a voltage input that extends to the lower rail, which is ground in this case (e.g., LM358).
- Constant transfer ratio: Due to the high differential impedance of the current source, the transfer ratio of the voltage feedback divider remains constant.
- Linearity and stability: When considering the stability of the feedback system, one must pay attention to the fact that the DC/DC converter is not fully linear. Typically, sufficient output capacitance must be provided to ensure feedback stability and low ripple across the entire voltage and current range.
- Feedback depth: Because a high-impedance current source is used for injection into the resistive divider, the effective depth of the negative feedback loop varies less than it would with a programmable resistive divider.
- Discharging capacitance: Some circuits may struggle to discharge output capacitance when the DC/DC converter is suddenly programmed to a lower voltage under a weak load. These cases may benefit from the use of bidirectional converters utilizing synchronous rectification.
As shown in the conceptual schematic (Figure 1), the target output voltage V_out as a function of current I is given by the following formula:
V_out(I) = V_ref * (1 + R1/R2) + R1 * I

Figure 1 This diagram shows a conceptual schematic of the proposed design.
As detailed in the full schematic (Figure 2), the output voltage control remains linear up to the clipping condition, which is typically the preferred behavior for linear control.

Figure 2 The full schematic details of a DC/DC converter providing up to 60 W in a voltage range of 2 V to 200 V, linearly controlled by a ground-referenced voltage input.
For this specific implementation, the output voltage is calculated as:
V_out(I) = V_ref * (1 + R7/R8) + R7 * I – (V_d – V_ref) * R7/R1
The current I, dependent on the input voltage V_in, is:
I = I(V_in) = min(V_ref / R10, (V_in / R10) * (1 + R9/R11))
During a V_in overdrive situation, the maximum output voltage for this circuit corresponds to the MOSFET (Q3) being fully open. The output voltage is then:
V_out = V_ref * (1 + R7/Rp)
where Rp is calculated as:
Rp = (R8 * R10) / (R8 + R10)
Advantages of the two-phase flyback approachThis DC/DC converter is built as a two-phase flyback using a low-cost Micrel MIC3808 controller (Figure 3). Similar controllers from other manufacturers, such as the Texas Instruments UCC38083, can also be used in similar configurations.
 |
 |
Figure 3 A PCB implementation of the design (left) was fabricated and in-lab tested (right).
Using a two-phase flyback approach offers several advantages over one-phase flyback or boost converters:
- Magnetic core saturation: An extensive, guaranteed 50% off-time for each transistor allows for better handling of loading conditions across a wide range of output voltages, preventing magnetic saturation of the core.
- Filtering: A two-phase converter provides better conditions for input and output filters, which is especially important under highly variable load situations.
- Component sizing: Using two phases allows the delivery of higher power using low-cost, mass-produced SMD coupled inductors rather than larger, more expensive magnetics.
- Cost efficiency: The cost of the DC/DC controller IC is often lower for push-pull type controllers compared to one-phase flyback or boost controllers. The cost of adding the second phase (MOSFET, inductor, diode) is usually much smaller than the savings on the controller.
Here are some experimental measurements results from this board (Figures 4-6).
- One can see perfect linear control of the output voltage.
- The idle power consumption is about 0.36 W while high power efficiency is approaching 78%.

Figure 4 This graph illustrates output voltage vs input voltage for the design.

Figure 5 This graph illustrates output power vs input power for the design.

Figure 6 This table details actual measurements for the lab-tested PCB prototype.
One thing that should be mentioned is that at light power with a small output capacitor, the DC/DC output may go through some slow (10-20 msec) and irregular oscillations. An example 90 V, 1.5 W output is shown in Figure 7.

Figure 7 Example oscillations at light output power (1.5 W) with a small output capacitor.
The ripple is quite small—0.1 V or so—and disappears in higher power output applications. Unfortunately, the non-linear nature of energy conversion in flyback DC/DC configurations makes them impossible to avoid across some subset range of all possible outputs.
To avoid this issue, the general recommendation is to have a large enough output capacitor; what’s important here are the output load characteristics. One can also change the feedback loop gain by setting a suitable value for the compensation capacitor (C8 in the schematic), but this alternative approach will also slow down the reaction time of the DC/DC feedback.
Nikolay Pavlov is an electronics/sensors hardware R&D engineer specializing in circuit analysis, component selection, electromagnetic modeling and signal processing. Outside of professional hardware design, he is an amateur radio operator with a deep interest in RF technology, Morse code, and shortwave radio operations.
Related Content
- Creating higher voltages, part 1: Voltage boosters
- Creating higher voltages, part 2: Voltage multipliers
The post A wide-range, linearly-programmable DC/DC converter appeared first on EDN.
BluGlass highlights September-quarter activities
Murata Launches World’s Smallest RF / Microwave Coaxial Connectors
Murata Manufacturing has begun mass production of the SWL series MM8330-2600RJ5 and MM8330-2600RK20, the world’s smallest RF / microwave coaxial connectors with a switch. Measuring just 1.0 mm × 1.0 mm × 0.55 mm, the new connectors reduce PCB mounting area by approximately 40% compared with Murata’s previous SWJ series.
When used with dedicated probes, the SWL series reduces its PCB footprint, including the keep-out area, by approximately 60% compared with Murata’s previous SWJ series. As wireless devices incorporate more functionality, rising component counts are placing increasing pressure on limited PCB space. RF test connectors require not only mounting area for the connector itself, but also sufficient clearance around the component for probe access during circuit measurement.
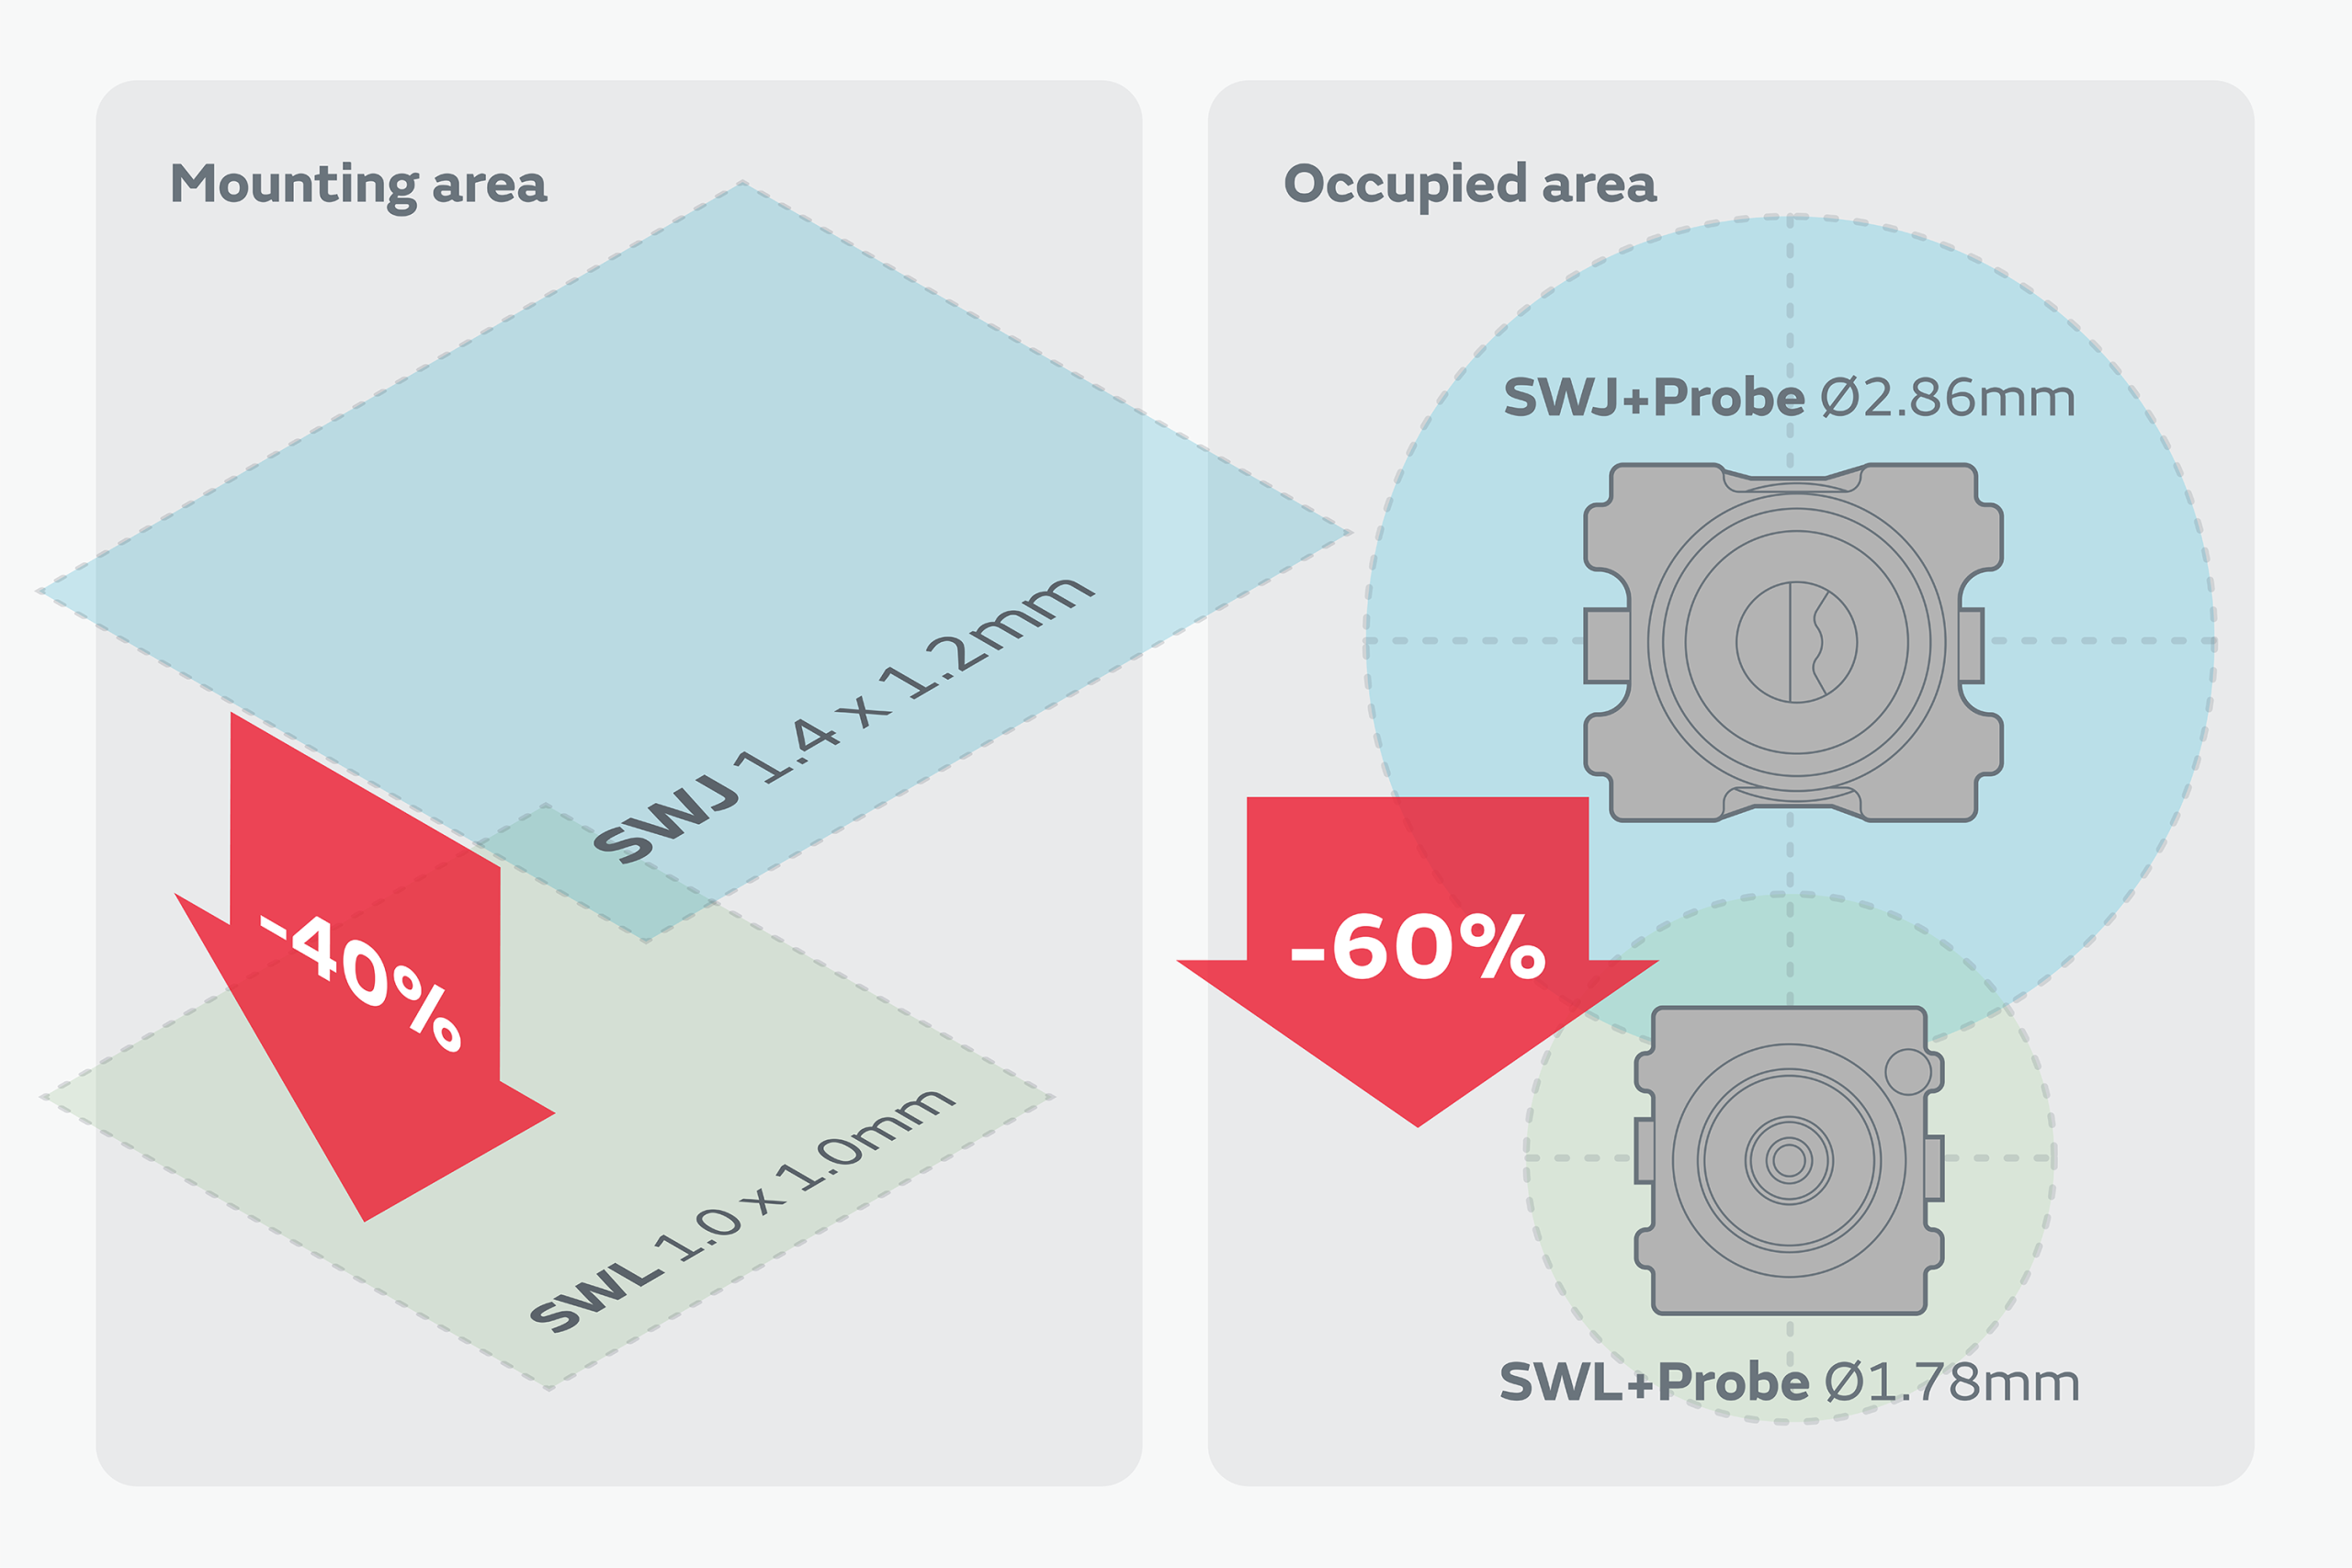 Murata’s SWL Series Reduces PCB Mounting Area by Approximately 40% and Probe-Related Occupied Area by Approximately 60% Compared with the Previous SWJ Series
Reducing the Space Required for RF Measurement
Murata addresses these constraints with a proprietary structure that combines its RF and mechanical design technologies. The design achieves miniaturization while maintaining low RF transmission loss and mechanical robustness. At 1.0 mm × 1.0 mm × 0.55 mm, the SWL series is smaller than Murata’s previous SWJ series, which measures 1.4 mm × 1.2 mm × 0.65 mm, allowing greater flexibility in PCB component placement.
When used with the dedicated automatic or manual probe, the world’s smallest Coaxial Connectors require less clearance around the test point. This reduces the total board area required for RF measurement. Murata plans to commence mass production of these dedicated probes in December 2026.
Supporting Frequencies up to 15 GHzThe SWL series supports a frequency range from DC to 15 GHz with a nominal impedance of 50 Ω. The MM8330-2600RJ5 is supplied on reels of 5,000 pieces, while the MM8330-2600RK20 is supplied on reels of 20,000 pieces. Murata will continue developing smaller electronic components and solutions that enable more effective use of limited PCB space, supporting higher-performance and more compact smartphones and wearable devices.
The post Murata Launches World’s Smallest RF / Microwave Coaxial Connectors appeared first on ELE Times.
Nordic Semiconductor expands the nRF54L series with the new nRF54LC10A multiprotocol SoC
Nordic Semiconductor, a global leader in low-power wireless connectivity solutions, unveils the nRF54LC10A System-on-Chip (SoC), which supports Bluetooth® Low Energy (LE), Bluetooth Channel Sounding, Thread, Zigbee and Matter. Developers building small, cost-sensitive connected products can now hit aggressive size and cost targets without sacrificing protocols, security features or a complete software ecosystem – a trade-off that has defined this category for years.
Full wireless capabilities in a reduced form factorThe entry-level nRF54LC10A is the smallest and lowest-power multiprotocol SoC in the nRF54L series, combining a simple MCU with a multiprotocol radio in a 1.9 × 2.3 mm chip-scale package. It comes with 1 MB of non-volatile memory (NVM), 192 KB of RAM and a set of peripherals sized for simple connected products. Its advanced security features, Arm® TrustZone® isolation and protection against physical attacks, combined with support for FOTA and remote observability in Nordic’s nRF Cloud services, let developers meet regulatory requirements while keeping products secure and maintainable in the field.
«Trade-offs have often been the challenge when it comes to entry-level products», says Øyvind Strøm, EVP Short-Range at Nordic Semiconductor. «The nRF54LC10A brings the protocols, advanced security and software ecosystem of the nRF54L series into a small, cost-sensitive device, enabling developers to build simple products without sacrificing capabilities.»
Developers can easily scale and upgrade their designs as requirements change, since every device in the nRF54L series runs the same qualified wireless stacks, embedded software and tools.
«The nRF54LC10A brings the protocols, advanced security and software ecosystem of the nRF54L series into a small, cost-sensitive device, enabling developers to build simple products without sacrificing capabilities.»
Øyvind Strøm, EVP Short-Range, Nordic Semiconductor
Designed for small IoT devices and high-volume deploymentsThe nRF54LC10A addresses two key application segments. The first is Bluetooth LE devices, which are expected to account for most deployments. Its combination of compact size, competitive cost and support for Bluetooth Channel Sounding makes it particularly well suited to asset trackers, while also enabling a wide range of other Bluetooth LE products that benefit from low power consumption and a reduced footprint.
The second is smart home applications. The device is intended for Thread and Zigbee accessories, as well as simpler Matter sensors whose functionality fits within the device’s memory profile. In home hub and Thread Border Router designs, the nRF54LC10A can also act as a Thread radio coprocessor (RCP), working alongside a host application processor or MCU to provide reliable Thread connectivity.
Designed for a long service lifeA 128 MHz Arm Cortex®-M33 core, supported by a RISC-V coprocessor, is paired with 1 MB of NVM, 192 KB of RAM and an essential set of peripherals made up of three SPI/TWI/UART instances and one ADC, delivering a preliminary value of 239 CoreMark®/mA and 503 CoreMark. The ultra-low-power operation comes from the rest of the series, built on a 22 nm process node with low-leakage RAM and Nordic’s multiprotocol radio design. The radio draws 4.0 mA in receive and 5.8 mA in transmit at 0 dBm, with a maximum TX power of +4 dBm; sensitivities are -97 dBm for Bluetooth LE 1M and -101 dBm for 802.15.4, while sleep current ranges from 0.5 µA to 1.6 µA. Three package options: two 1.9 × 2.3 mm chip-scale packages (CSP) and a QFN, which include the smallest footprint in the series.
AvailabilityThe nRF54LC10A is now available for sampling, with production expected by Q2 2027. Development kits will be generally available by Q1 2027. Contact Nordic’s sales department for samples and early-access development kits.
For more information, visit the Nordic Semiconductor website.
The post Nordic Semiconductor expands the nRF54L series with the new nRF54LC10A multiprotocol SoC appeared first on Open Electronics.
Why reliability metrics must dictate advanced-node physical implementation flow

Every physical design engineer has lived some version of this schedule. The block closes timing in place-and-route. The team celebrates for about a day. Then sign-off extraction comes back, the IR drop analysis finds hotspots nobody modeled, electromigration flags show up on nets that were routed weeks ago, and the fixes for both move the timing picture that was supposedly final. The last couple of weeks before tape-out turn into a negotiation between three problems that were treated as separate jobs all along.
That workflow was survivable at older nodes. The classical ASIC flow was linear: power, performance, and area drove the early iterations, schedule sat on top of everything, and physical verification, EM, and IR drop compliance waited at the end as sign-off routines.
If a reliability problem surfaced late, there was usually enough margin somewhere to patch it. At advanced geometries the margins that made it possible are mostly gone, and the patching approach now produces fragile silicon: designs that pass timing or power may not be reliable.
The argument of this article is simple. Dynamic voltage drops, electromigration, and timing are not three axes to be optimized in sequence. They are one physical system. A cell’s delay depends on the voltage it actually receives. The voltage it receives depends on what its neighbors are doing. What its neighbors are doing depends on placement and switching density, which the timing engine itself decided.
Teams that treat these as a single ecosystem during implementation tape out on schedule. Teams that treat them as separate sign-off gates spend their final weeks discovering interactions all at once.
Transient voltage and signal velocity are the same problem
Start with the interaction that breaks timing closure most often: dynamic IR drop. Static timing analysis models cell delay against nominal supply rails. Real silicon does not run on nominal rails. Inside a high-utilization block, hundreds of thousands of standard cells switch in the same clock window, the power delivery network sees a sharp transient current demand, and the local rail voltage sags for exactly the cycles when the switching happens.
Gate delay degrades as supply voltage falls, and not gently. The relationship is non-linear, so a modest local voltage droop slows the affected paths more than a first-order estimate suggests. Now consider what the placement engine was doing while this trap was being set.
Asked to close setup timing locally, it packed high-switching cells tightly together, because dense placement shortens wires and helps delay. The result is a cluster that meets timing at nominal voltage and creates the transient drop that invalidates the timing the moment real switching activity runs through it.
The standard late-stage responses make this worse, which is the part teams learn the hard way. A path fails after IR analysis, so the engineer sizes up cells or inserts buffers to recover slack. But the failing region is failing because it’s starved of voltage. Adding buffers adds capacitive load and more switching current to the same starved region.
The drop deepens, the repaired path recovers, and two neighboring paths fall over instead. Anyone who has chased timing violations around a block in the final ECO rounds has seen violations migrate like this. The violations are not independent; the voltage is the shared variable (see figure below).

See the feedback loop between placement density, dynamic IR drop, and cell delay. Dense placement of high-switching logic deepens local voltage droop, which slows the very paths the density was meant to speed up, and late buffering adds load to the same starved region. Source: Author
Breaking the cycle means treating local voltage stability as an input to placement rather than a verdict delivered afterward. In practice, that means distributed density bounds so that peak switching activity is spread structurally across the block, spacing heuristics around known high-activity logic, and early dynamic IR estimation on global-route data while placement can still move. None of this requires exotic tooling; it requires deciding that the power delivery network (PDN) and the placer are working on the same problem.
Electromigration is a layout decision
Electromigration (EM) is a reliability issue that happens over time. It’s a slow, progressive physical wear-out—EM is the gradual displacement of metal atoms under sustained current density over time. Whether a wire suffers is decided by current direction, current density, and the cross-section of the wire. All three are set during implementation, mostly during routing.
The failure pattern repeats across programs. An implementation team chases frequency on a critical path and keeps raising drive strengths to get there. Higher drive strength means higher switching current through the interconnect feeding those cells.
On the thin metal layers of an advanced node, that current density can sit past the physical limit of the wire for years of operating life. Nothing fails at tape-out. The resistance of the line degrades progressively in the field until it opens, and the failure arrives long after the design team has moved on.
When EM does get caught at sign-off, the fix is brutal precisely because it comes late. Widening wires or expanding route area on a fully routed, congested block in the last few weeks of tape-out displaces signal tracks that were already closed. Timing reopens. New violations cascade out of the fix for the old ones.
Compare that with setting the rules before detailed routing runs: non-default routing rules on the nets that need them, selective wire widening and layer promotion for long-distance and high-frequency routes, and current-density budgets attached to the nets that carry the most switching current. The layout gets pre-conditioned to absorb the stress, and it costs a fraction of the late fix because the router was never allowed to paint the design into the corner.
From sign-off gate to diagnostic loop
Underneath both problems sits a management habit: reliability metrics get tracked as hurdles at the end of the program instead of variables during it. Three changes in how a team watches its own progress do most of the work.
First, retire the green static timing analysis (STA) report as a milestone. A place-and-route run showing zero violations before physical verification, EM, and IR extraction is not evidence of convergence. If the timing was achieved by overloading cell drive strengths or crowding macro interfaces, the layout will change when the reliability fixes land, and the green report will turn out to have measured a design that was never going to ship. Report timing alongside the state of the reliability checks, or do not report it as progress.
Second, track the trade-offs explicitly instead of letting each team optimize its own number. Utilization decisions move local thermal and voltage behavior. Total negative slack trends mean different things at different voltage scenarios, so run the analysis across the scenarios the part will actually see and watch whether the design converges uniformly or only at a specific corner. A design that converges at one corner and frays at the others is telling you where the field returns will come from.
Third, build the feedback loops into the flow rather than into the org chart. The older model has separate groups running sign-off checks near the end of the program and throwing reports over the wall. The model that works runs early, approximate versions of the same checks inside the implementation loop: global-route estimates feeding statistical power integrity and EM screens, placement-time density checks against switching activity, and results returned to the engineer who can still move things. Approximate and early beats exact and late, because the cost of correcting a structural problem rises by orders of magnitude between placement and final routing.
What maturity actually looks like
None of this argues for lower performance targets. High frequency and low power are still the point. The claim is narrower: at advanced nodes those targets are reached as a byproduct of a physically stable layout, not by optimizing timing in isolation and negotiating with physics afterward. Dynamic voltage drop, electromigration, and physical verification belong in the implementation recipe from the first floorplan, as constraints the flow optimizes against, not as audits the flow survives at the end.
Programs that make this shift stop experiencing tape-out as volatile final months. The sign-off runs confirm what the early loops already showed. That predictability, more than any single PPA number, is what a mature physical design organization is actually selling to the rest of the program.
Vignesh Sunderrajan is a silicon design professional with 15 years of experience in implementing high-performance mobile, laptop, and networking chips, contributing to complex CPU and SoC programs from RTL to final layout at advanced technology nodes.
Related Content
- Relational physical design: no absolutes
- Accelerating Silicon Design for Physical AI
- Physical Design Flow Taps Partition Layout
- Current physical design tools come up short
- Exploring new design flows—physical layout
The post Why reliability metrics must dictate advanced-node physical implementation flow appeared first on EDN.
Сталий розвиток університетського кампусу: екологічна відповідальність та раціональне використання ресурсів у КПІ

Сучасний університет — це не лише освітній і науковий простір, а й складна інфраструктурна система, функціонування якої потребує значних обсягів енергетичних, водних та інших природних ресурсів. Тому важливою складовою розвитку КПІ ім. Ігоря Сікорського є впровадження принципів сталого розвитку, енергоефективності та екологічної відповідальності в управління університетським кампусом.
IronEar: the privacy-first audio sensor that recognises 500 sounds on-device
IronEar is an open source, privacy-first audio sensor that recognises more than 500 types of sound thanks to an AI running on board. The audio never leaves the device, so it never ends up on any server. The node is designed for the home and integrates with Home Assistant via MQTT. It can also communicate over LoRa when Wi-Fi is not available. That makes it an alternative to cameras for home surveillance, because it recognises the important sounds without compromising privacy.
The heart of the project is an Espressif ESP32-S3-WROOM-1 module with 16 MB of flash and 8 MB of PSRAM. This memory budget is what keeps the classification model and the audio buffers stored locally. The LoRa radio relies on a Semtech SX1262, while a Quectel LC76G completes the node’s feature set. The result is a self-contained sensor that does not depend on the home network to work.
Three MEMS microphones and the TinyEar classification modelSound capture is handled by three Infineon IM73D122 MEMS microphones, arranged in a triangular array. This geometry lets the node pick up sound from several points and handle directions of arrival better. Recognition, on the other hand, is handled by TinyEar, a port of Google’s YAMNet audio classification model. Classification happens locally about once per second, without recording audio or sending it to a server.
 The internal hardware of IronEar
The way it works comes down to a few steps:
- The three MEMS microphones pick up the sound of the environment.
- TinyEar classifies the sound locally about once per second.
- The result becomes a sensor event, with no audio stored.
- The node publishes it over MQTT to Home Assistant.
- If Wi-Fi is missing, the SX1262 module sends it over a Meshtastic channel.
The scene learning feature adds a useful layer in the home. The user records the sound characteristics of a room for a few minutes and the node then learns to recognise that particular acoustic scene. So it is not only good for telling one sharp sound apart, but also for understanding the state of an environment over time. Anyone who wants to rebuild the project will find the Crowd Supply campaign a starting point for understanding what is needed and how the node is put together.
MQTT on Home Assistant and a private Meshtastic channelFor home use, IronEar connects to Home Assistant through MQTT. That way a detected sound can be treated like any other sensor input, for example to turn on a light or send a notification. On top of that, the same event structure applies to all recognised sounds, so automations only have to be written once.
When Wi-Fi is not available, IronEar uses a LoRa module based on the Semtech SX1262 and communicates over a private Meshtastic channel. This is the part that makes the node interesting outside the home too, for example in a garage or an outbuilding. The sensor does not depend on local network coverage and keeps a low-power communication path open. All of it without ever letting the audio leave the device.
The numbers help frame the project. The ESP32-S3-WROOM-1 module provides 16 MB of flash and 8 MB of PSRAM. There are three Infineon IM73D122 MEMS microphones, arranged in a triangular array. IronEar recognises more than 500 different types of sound and classification happens locally about once per second. These figures explain why the node can work on its own, with no cloud and without recording anything.
For anyone who wants to rebuild the project, the software side relies on TinyEar and YAMNet for classification, on MQTT and Home Assistant for integration, and on Meshtastic for the LoRa channel. The hardware revolves around the ESP32-S3-WROOM-1, IM73D122, SX1262 and LC76G. The Crowd Supply campaign gathers the project and the details for anyone who wants to build it or follow it.
Source: https://www.crowdsupply.com/ironear-technologies/ironear
The post IronEar: the privacy-first audio sensor that recognises 500 sounds on-device appeared first on Open Electronics.
EEVblog 1784 - Claude Code Reverse Engineer 121GW Firmware SUCCESS!
💛 Вебінар "Від ідеї до інституційної практики: як інтегрувати Citizen Science в дослідницьку діяльність університету"

Бібліотека КПІ запрошує дослідників КПІ ім. Ігоря Сікорського та усіх охочих долучитися до вебінару «Від ідеї до інституційної практики: як інтегрувати Citizen Science в дослідницьку діяльність університету».
⭐ Студентська конференція та конкурс студентських наукових робіт з англійської мови “Advances in Science and Technology"

Запрошуємо взяти участь у Міжнародному конкурсі студентських наукових робіт «Досягнення в науці та техніці» та онлайн-конференції з досліджень та розробок, що є унікальною можливістю дослідити передові дослідження та запропонувати інноваційні рішення глобальних проблем. Це ваш шанс продемонструвати свої навички, розширити свої знання та вплинути на майбутнє науки і техніки.
Сторінки