

Новини світу мікро- та наноелектроніки
A wide-range, linearly-programmable DC/DC converter

This Design Idea presents a simple, low-cost, highly flexible, and scalable DC/DC converter.
- The output is linearly programmed by an external, ground-referenced voltage.
- The design is a two-phase flyback converter powered by an input of 15 V to 30 V.
- It provides an output voltage ranging from 0 V to 200 V with a maximum power output of up to 60 W.
- The system is built around a MIC3808/MIC3809 or a similar push-pull PWM controller.
Wow the engineering world with your unique design: Design Ideas Submission Guide
The ChallengeSome applications demand significant DC power delivered at a precisely controlled voltage that may vary over a wide range. Traditional solutions for this requirement often involve:
- Linear regulators: Suffer from low efficiency and high power dissipation.
- PWM step-down converters: Can only generate voltages lower than the rail voltage and lack a voltage feedback loop unless explicitly implemented.
- Digital potentiometers / multiplying DACs: An alternative is substituting the resistive feedback dividers of power control ICs with digital potentiometers. However, this requires digital rather than analog control. It also causes massive changes in the voltage feedback loop gain over the adjustment range, which can destabilize the output voltage.
This simple, generic solution converts power control ICs with a voltage feedback input to allow for wide-range, linearly adjustable DC/DC conversion.
In the preferred implementation, a small-value, voltage-controlled current source is used to remove current from the sensing point of the DC/DC controlling loop’s voltage feedback divider.
- This proposed current source is built using a small MOSFET (such as a 2N7002) and an operational amplifier.
- It is often preferable to use op-amps with a voltage input that extends to the lower rail, which is ground in this case (e.g., LM358).
- Constant transfer ratio: Due to the high differential impedance of the current source, the transfer ratio of the voltage feedback divider remains constant.
- Linearity and stability: When considering the stability of the feedback system, one must pay attention to the fact that the DC/DC converter is not fully linear. Typically, sufficient output capacitance must be provided to ensure feedback stability and low ripple across the entire voltage and current range.
- Feedback depth: Because a high-impedance current source is used for injection into the resistive divider, the effective depth of the negative feedback loop varies less than it would with a programmable resistive divider.
- Discharging capacitance: Some circuits may struggle to discharge output capacitance when the DC/DC converter is suddenly programmed to a lower voltage under a weak load. These cases may benefit from the use of bidirectional converters utilizing synchronous rectification.
As shown in the conceptual schematic (Figure 1), the target output voltage V_out as a function of current I is given by the following formula:
V_out(I) = V_ref * (1 + R1/R2) + R1 * I

Figure 1 This diagram shows a conceptual schematic of the proposed design.
As detailed in the full schematic (Figure 2), the output voltage control remains linear up to the clipping condition, which is typically the preferred behavior for linear control.

Figure 2 The full schematic details of a DC/DC converter providing up to 60 W in a voltage range of 2 V to 200 V, linearly controlled by a ground-referenced voltage input.
For this specific implementation, the output voltage is calculated as:
V_out(I) = V_ref * (1 + R7/R8) + R7 * I – (V_d – V_ref) * R7/R1
The current I, dependent on the input voltage V_in, is:
I = I(V_in) = min(V_ref / R10, (V_in / R10) * (1 + R9/R11))
During a V_in overdrive situation, the maximum output voltage for this circuit corresponds to the MOSFET (Q3) being fully open. The output voltage is then:
V_out = V_ref * (1 + R7/Rp)
where Rp is calculated as:
Rp = (R8 * R10) / (R8 + R10)
Advantages of the two-phase flyback approachThis DC/DC converter is built as a two-phase flyback using a low-cost Micrel MIC3808 controller (Figure 3). Similar controllers from other manufacturers, such as the Texas Instruments UCC38083, can also be used in similar configurations.
 |
 |
Figure 3 A PCB implementation of the design (left) was fabricated and in-lab tested (right).
Using a two-phase flyback approach offers several advantages over one-phase flyback or boost converters:
- Magnetic core saturation: An extensive, guaranteed 50% off-time for each transistor allows for better handling of loading conditions across a wide range of output voltages, preventing magnetic saturation of the core.
- Filtering: A two-phase converter provides better conditions for input and output filters, which is especially important under highly variable load situations.
- Component sizing: Using two phases allows the delivery of higher power using low-cost, mass-produced SMD coupled inductors rather than larger, more expensive magnetics.
- Cost efficiency: The cost of the DC/DC controller IC is often lower for push-pull type controllers compared to one-phase flyback or boost controllers. The cost of adding the second phase (MOSFET, inductor, diode) is usually much smaller than the savings on the controller.
Here are some experimental measurements results from this board (Figures 4-6).
- One can see perfect linear control of the output voltage.
- The idle power consumption is about 0.36 W while high power efficiency is approaching 78%.

Figure 4 This graph illustrates output voltage vs input voltage for the design.

Figure 5 This graph illustrates output power vs input power for the design.

Figure 6 This table details actual measurements for the lab-tested PCB prototype.
One thing that should be mentioned is that at light power with a small output capacitor, the DC/DC output may go through some slow (10-20 msec) and irregular oscillations. An example 90 V, 1.5 W output is shown in Figure 7.

Figure 7 Example oscillations at light output power (1.5 W) with a small output capacitor.
The ripple is quite small—0.1 V or so—and disappears in higher power output applications. Unfortunately, the non-linear nature of energy conversion in flyback DC/DC configurations makes them impossible to avoid across some subset range of all possible outputs.
To avoid this issue, the general recommendation is to have a large enough output capacitor; what’s important here are the output load characteristics. One can also change the feedback loop gain by setting a suitable value for the compensation capacitor (C8 in the schematic), but this alternative approach will also slow down the reaction time of the DC/DC feedback.
Nikolay Pavlov is an electronics/sensors hardware R&D engineer specializing in circuit analysis, component selection, electromagnetic modeling and signal processing. Outside of professional hardware design, he is an amateur radio operator with a deep interest in RF technology, Morse code, and shortwave radio operations.
Related Content
- Creating higher voltages, part 1: Voltage boosters
- Creating higher voltages, part 2: Voltage multipliers
The post A wide-range, linearly-programmable DC/DC converter appeared first on EDN.
BluGlass highlights September-quarter activities
Murata Launches World’s Smallest RF / Microwave Coaxial Connectors
Murata Manufacturing has begun mass production of the SWL series MM8330-2600RJ5 and MM8330-2600RK20, the world’s smallest RF / microwave coaxial connectors with a switch. Measuring just 1.0 mm × 1.0 mm × 0.55 mm, the new connectors reduce PCB mounting area by approximately 40% compared with Murata’s previous SWJ series.
When used with dedicated probes, the SWL series reduces its PCB footprint, including the keep-out area, by approximately 60% compared with Murata’s previous SWJ series. As wireless devices incorporate more functionality, rising component counts are placing increasing pressure on limited PCB space. RF test connectors require not only mounting area for the connector itself, but also sufficient clearance around the component for probe access during circuit measurement.
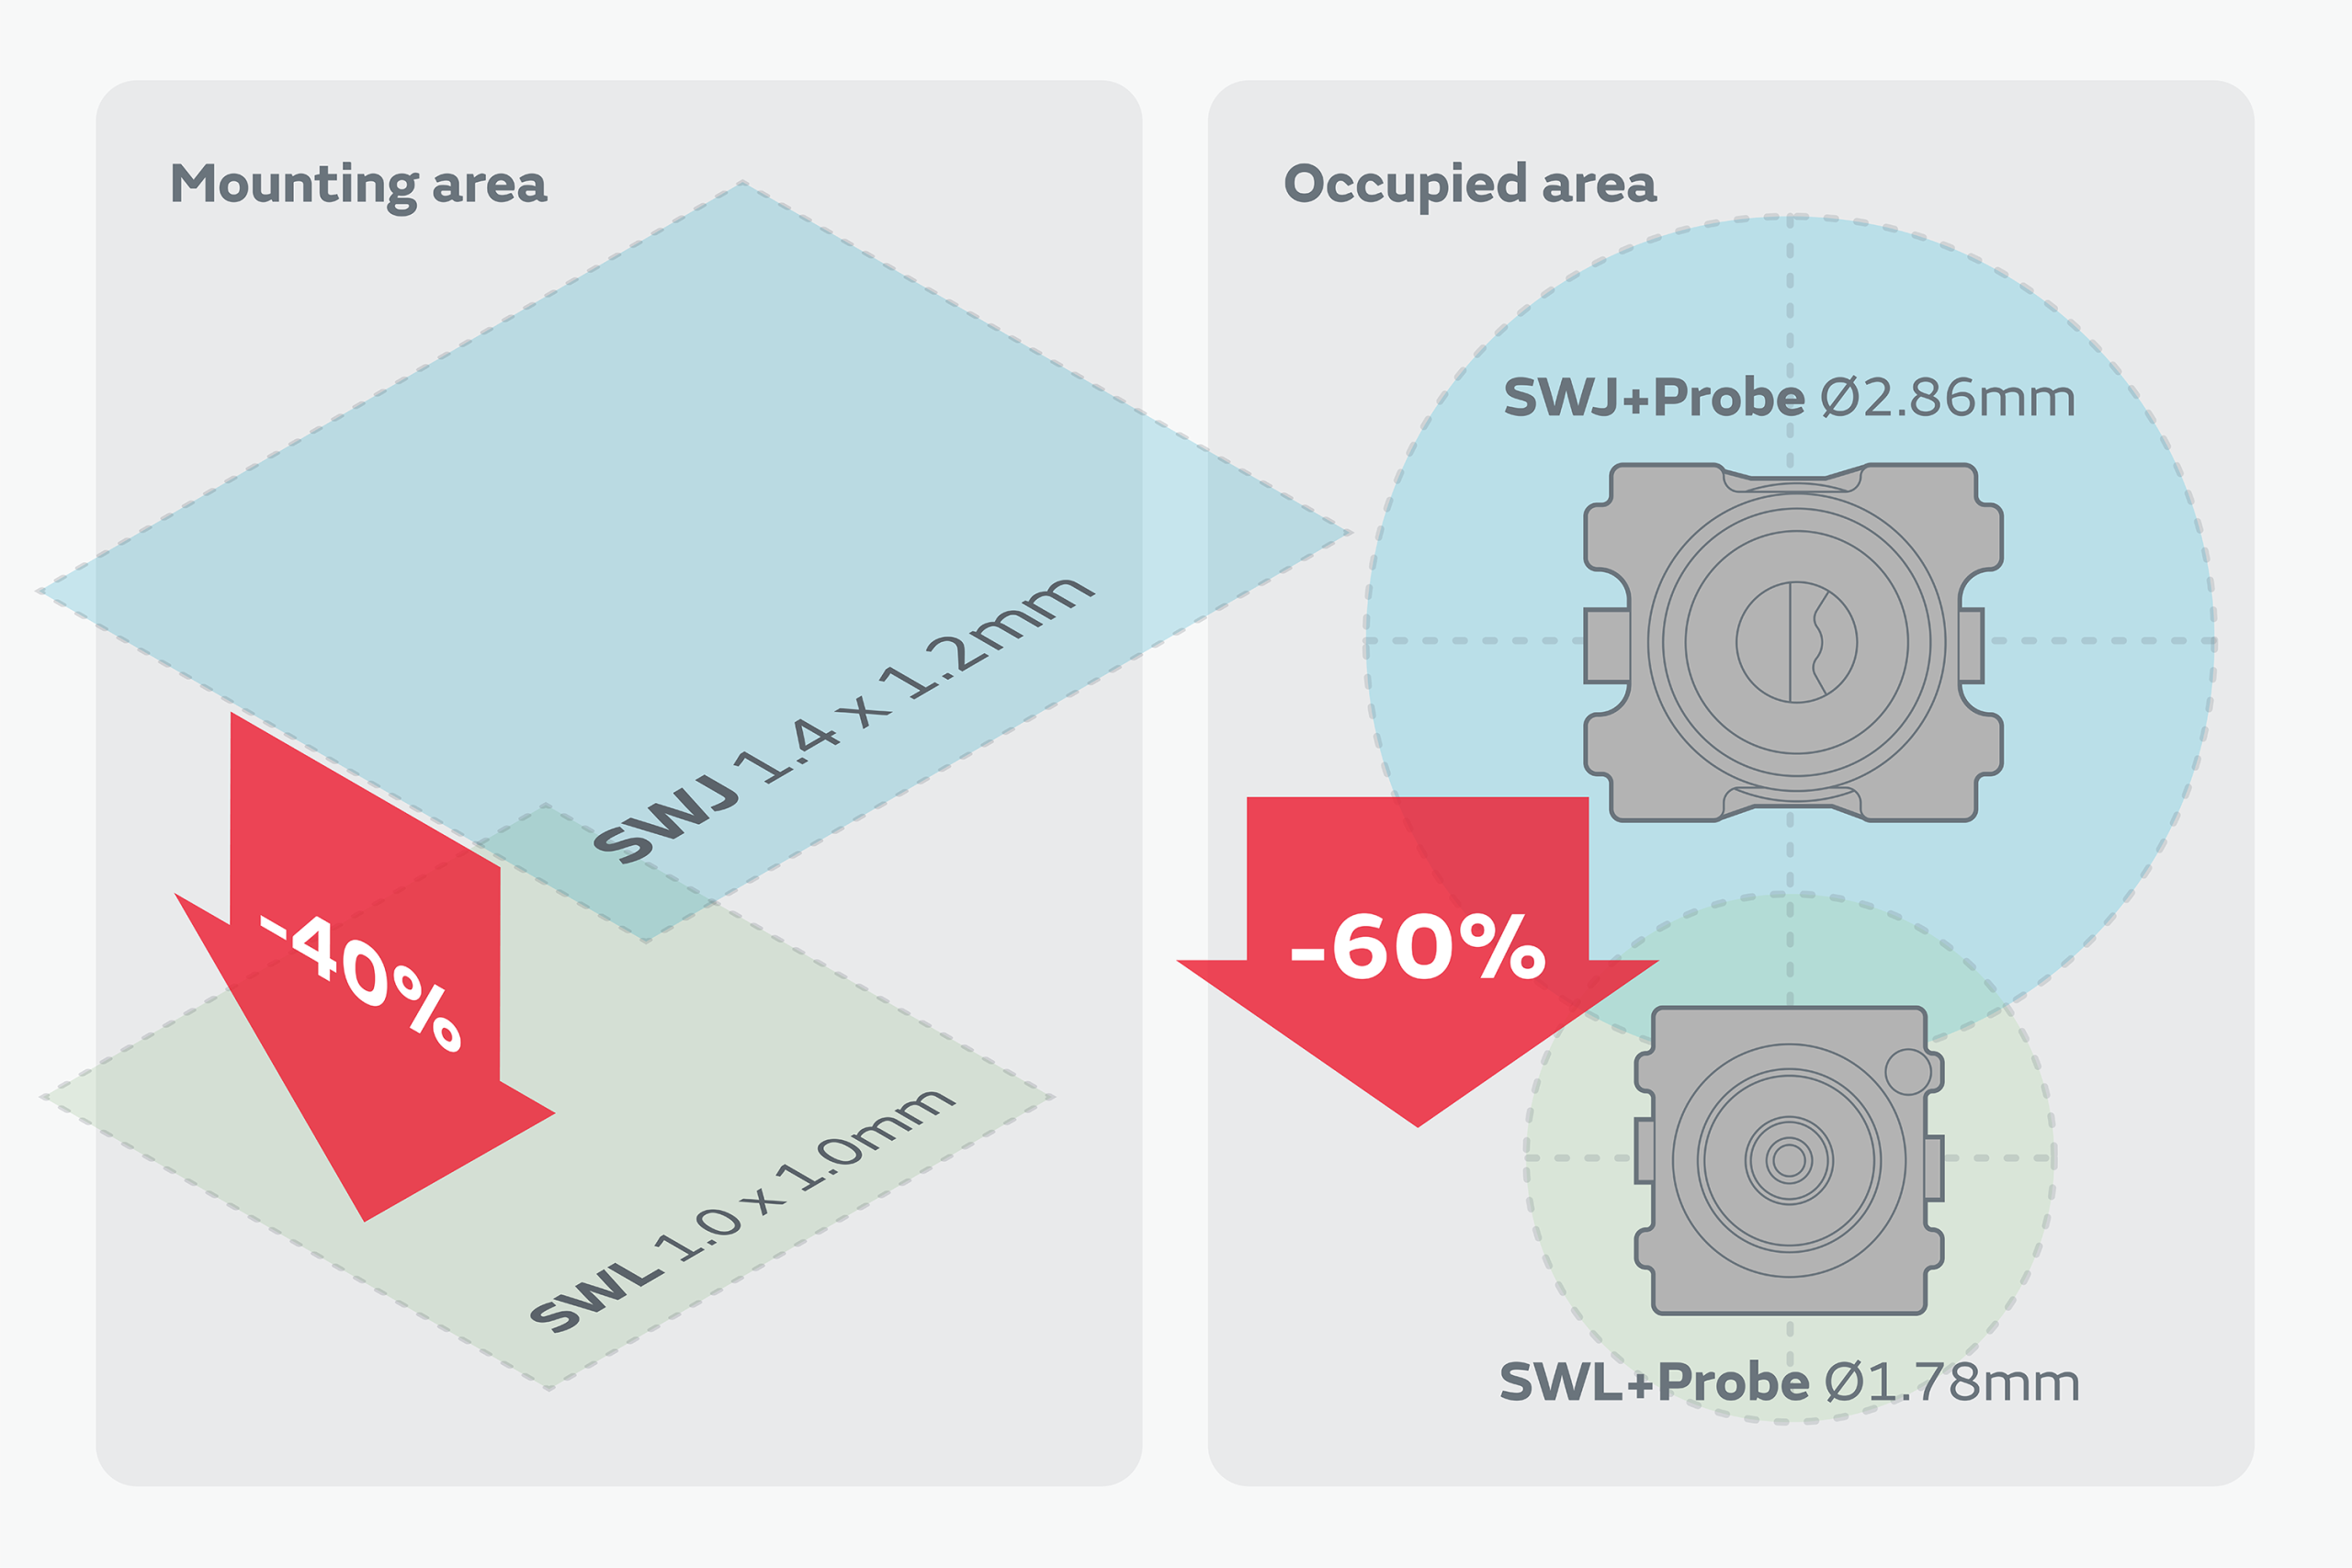 Murata’s SWL Series Reduces PCB Mounting Area by Approximately 40% and Probe-Related Occupied Area by Approximately 60% Compared with the Previous SWJ Series
Reducing the Space Required for RF Measurement
Murata addresses these constraints with a proprietary structure that combines its RF and mechanical design technologies. The design achieves miniaturization while maintaining low RF transmission loss and mechanical robustness. At 1.0 mm × 1.0 mm × 0.55 mm, the SWL series is smaller than Murata’s previous SWJ series, which measures 1.4 mm × 1.2 mm × 0.65 mm, allowing greater flexibility in PCB component placement.
When used with the dedicated automatic or manual probe, the world’s smallest Coaxial Connectors require less clearance around the test point. This reduces the total board area required for RF measurement. Murata plans to commence mass production of these dedicated probes in December 2026.
Supporting Frequencies up to 15 GHzThe SWL series supports a frequency range from DC to 15 GHz with a nominal impedance of 50 Ω. The MM8330-2600RJ5 is supplied on reels of 5,000 pieces, while the MM8330-2600RK20 is supplied on reels of 20,000 pieces. Murata will continue developing smaller electronic components and solutions that enable more effective use of limited PCB space, supporting higher-performance and more compact smartphones and wearable devices.
The post Murata Launches World’s Smallest RF / Microwave Coaxial Connectors appeared first on ELE Times.
Nordic Semiconductor expands the nRF54L series with the new nRF54LC10A multiprotocol SoC
Nordic Semiconductor, a global leader in low-power wireless connectivity solutions, unveils the nRF54LC10A System-on-Chip (SoC), which supports Bluetooth® Low Energy (LE), Bluetooth Channel Sounding, Thread, Zigbee and Matter. Developers building small, cost-sensitive connected products can now hit aggressive size and cost targets without sacrificing protocols, security features or a complete software ecosystem – a trade-off that has defined this category for years.
Full wireless capabilities in a reduced form factorThe entry-level nRF54LC10A is the smallest and lowest-power multiprotocol SoC in the nRF54L series, combining a simple MCU with a multiprotocol radio in a 1.9 × 2.3 mm chip-scale package. It comes with 1 MB of non-volatile memory (NVM), 192 KB of RAM and a set of peripherals sized for simple connected products. Its advanced security features, Arm® TrustZone® isolation and protection against physical attacks, combined with support for FOTA and remote observability in Nordic’s nRF Cloud services, let developers meet regulatory requirements while keeping products secure and maintainable in the field.
«Trade-offs have often been the challenge when it comes to entry-level products», says Øyvind Strøm, EVP Short-Range at Nordic Semiconductor. «The nRF54LC10A brings the protocols, advanced security and software ecosystem of the nRF54L series into a small, cost-sensitive device, enabling developers to build simple products without sacrificing capabilities.»
Developers can easily scale and upgrade their designs as requirements change, since every device in the nRF54L series runs the same qualified wireless stacks, embedded software and tools.
«The nRF54LC10A brings the protocols, advanced security and software ecosystem of the nRF54L series into a small, cost-sensitive device, enabling developers to build simple products without sacrificing capabilities.»
Øyvind Strøm, EVP Short-Range, Nordic Semiconductor
Designed for small IoT devices and high-volume deploymentsThe nRF54LC10A addresses two key application segments. The first is Bluetooth LE devices, which are expected to account for most deployments. Its combination of compact size, competitive cost and support for Bluetooth Channel Sounding makes it particularly well suited to asset trackers, while also enabling a wide range of other Bluetooth LE products that benefit from low power consumption and a reduced footprint.
The second is smart home applications. The device is intended for Thread and Zigbee accessories, as well as simpler Matter sensors whose functionality fits within the device’s memory profile. In home hub and Thread Border Router designs, the nRF54LC10A can also act as a Thread radio coprocessor (RCP), working alongside a host application processor or MCU to provide reliable Thread connectivity.
Designed for a long service lifeA 128 MHz Arm Cortex®-M33 core, supported by a RISC-V coprocessor, is paired with 1 MB of NVM, 192 KB of RAM and an essential set of peripherals made up of three SPI/TWI/UART instances and one ADC, delivering a preliminary value of 239 CoreMark®/mA and 503 CoreMark. The ultra-low-power operation comes from the rest of the series, built on a 22 nm process node with low-leakage RAM and Nordic’s multiprotocol radio design. The radio draws 4.0 mA in receive and 5.8 mA in transmit at 0 dBm, with a maximum TX power of +4 dBm; sensitivities are -97 dBm for Bluetooth LE 1M and -101 dBm for 802.15.4, while sleep current ranges from 0.5 µA to 1.6 µA. Three package options: two 1.9 × 2.3 mm chip-scale packages (CSP) and a QFN, which include the smallest footprint in the series.
AvailabilityThe nRF54LC10A is now available for sampling, with production expected by Q2 2027. Development kits will be generally available by Q1 2027. Contact Nordic’s sales department for samples and early-access development kits.
For more information, visit the Nordic Semiconductor website.
The post Nordic Semiconductor expands the nRF54L series with the new nRF54LC10A multiprotocol SoC appeared first on Open Electronics.
Why reliability metrics must dictate advanced-node physical implementation flow

Every physical design engineer has lived some version of this schedule. The block closes timing in place-and-route. The team celebrates for about a day. Then sign-off extraction comes back, the IR drop analysis finds hotspots nobody modeled, electromigration flags show up on nets that were routed weeks ago, and the fixes for both move the timing picture that was supposedly final. The last couple of weeks before tape-out turn into a negotiation between three problems that were treated as separate jobs all along.
That workflow was survivable at older nodes. The classical ASIC flow was linear: power, performance, and area drove the early iterations, schedule sat on top of everything, and physical verification, EM, and IR drop compliance waited at the end as sign-off routines.
If a reliability problem surfaced late, there was usually enough margin somewhere to patch it. At advanced geometries the margins that made it possible are mostly gone, and the patching approach now produces fragile silicon: designs that pass timing or power may not be reliable.
The argument of this article is simple. Dynamic voltage drops, electromigration, and timing are not three axes to be optimized in sequence. They are one physical system. A cell’s delay depends on the voltage it actually receives. The voltage it receives depends on what its neighbors are doing. What its neighbors are doing depends on placement and switching density, which the timing engine itself decided.
Teams that treat these as a single ecosystem during implementation tape out on schedule. Teams that treat them as separate sign-off gates spend their final weeks discovering interactions all at once.
Transient voltage and signal velocity are the same problem
Start with the interaction that breaks timing closure most often: dynamic IR drop. Static timing analysis models cell delay against nominal supply rails. Real silicon does not run on nominal rails. Inside a high-utilization block, hundreds of thousands of standard cells switch in the same clock window, the power delivery network sees a sharp transient current demand, and the local rail voltage sags for exactly the cycles when the switching happens.
Gate delay degrades as supply voltage falls, and not gently. The relationship is non-linear, so a modest local voltage droop slows the affected paths more than a first-order estimate suggests. Now consider what the placement engine was doing while this trap was being set.
Asked to close setup timing locally, it packed high-switching cells tightly together, because dense placement shortens wires and helps delay. The result is a cluster that meets timing at nominal voltage and creates the transient drop that invalidates the timing the moment real switching activity runs through it.
The standard late-stage responses make this worse, which is the part teams learn the hard way. A path fails after IR analysis, so the engineer sizes up cells or inserts buffers to recover slack. But the failing region is failing because it’s starved of voltage. Adding buffers adds capacitive load and more switching current to the same starved region.
The drop deepens, the repaired path recovers, and two neighboring paths fall over instead. Anyone who has chased timing violations around a block in the final ECO rounds has seen violations migrate like this. The violations are not independent; the voltage is the shared variable (see figure below).

See the feedback loop between placement density, dynamic IR drop, and cell delay. Dense placement of high-switching logic deepens local voltage droop, which slows the very paths the density was meant to speed up, and late buffering adds load to the same starved region. Source: Author
Breaking the cycle means treating local voltage stability as an input to placement rather than a verdict delivered afterward. In practice, that means distributed density bounds so that peak switching activity is spread structurally across the block, spacing heuristics around known high-activity logic, and early dynamic IR estimation on global-route data while placement can still move. None of this requires exotic tooling; it requires deciding that the power delivery network (PDN) and the placer are working on the same problem.
Electromigration is a layout decision
Electromigration (EM) is a reliability issue that happens over time. It’s a slow, progressive physical wear-out—EM is the gradual displacement of metal atoms under sustained current density over time. Whether a wire suffers is decided by current direction, current density, and the cross-section of the wire. All three are set during implementation, mostly during routing.
The failure pattern repeats across programs. An implementation team chases frequency on a critical path and keeps raising drive strengths to get there. Higher drive strength means higher switching current through the interconnect feeding those cells.
On the thin metal layers of an advanced node, that current density can sit past the physical limit of the wire for years of operating life. Nothing fails at tape-out. The resistance of the line degrades progressively in the field until it opens, and the failure arrives long after the design team has moved on.
When EM does get caught at sign-off, the fix is brutal precisely because it comes late. Widening wires or expanding route area on a fully routed, congested block in the last few weeks of tape-out displaces signal tracks that were already closed. Timing reopens. New violations cascade out of the fix for the old ones.
Compare that with setting the rules before detailed routing runs: non-default routing rules on the nets that need them, selective wire widening and layer promotion for long-distance and high-frequency routes, and current-density budgets attached to the nets that carry the most switching current. The layout gets pre-conditioned to absorb the stress, and it costs a fraction of the late fix because the router was never allowed to paint the design into the corner.
From sign-off gate to diagnostic loop
Underneath both problems sits a management habit: reliability metrics get tracked as hurdles at the end of the program instead of variables during it. Three changes in how a team watches its own progress do most of the work.
First, retire the green static timing analysis (STA) report as a milestone. A place-and-route run showing zero violations before physical verification, EM, and IR extraction is not evidence of convergence. If the timing was achieved by overloading cell drive strengths or crowding macro interfaces, the layout will change when the reliability fixes land, and the green report will turn out to have measured a design that was never going to ship. Report timing alongside the state of the reliability checks, or do not report it as progress.
Second, track the trade-offs explicitly instead of letting each team optimize its own number. Utilization decisions move local thermal and voltage behavior. Total negative slack trends mean different things at different voltage scenarios, so run the analysis across the scenarios the part will actually see and watch whether the design converges uniformly or only at a specific corner. A design that converges at one corner and frays at the others is telling you where the field returns will come from.
Third, build the feedback loops into the flow rather than into the org chart. The older model has separate groups running sign-off checks near the end of the program and throwing reports over the wall. The model that works runs early, approximate versions of the same checks inside the implementation loop: global-route estimates feeding statistical power integrity and EM screens, placement-time density checks against switching activity, and results returned to the engineer who can still move things. Approximate and early beats exact and late, because the cost of correcting a structural problem rises by orders of magnitude between placement and final routing.
What maturity actually looks like
None of this argues for lower performance targets. High frequency and low power are still the point. The claim is narrower: at advanced nodes those targets are reached as a byproduct of a physically stable layout, not by optimizing timing in isolation and negotiating with physics afterward. Dynamic voltage drop, electromigration, and physical verification belong in the implementation recipe from the first floorplan, as constraints the flow optimizes against, not as audits the flow survives at the end.
Programs that make this shift stop experiencing tape-out as volatile final months. The sign-off runs confirm what the early loops already showed. That predictability, more than any single PPA number, is what a mature physical design organization is actually selling to the rest of the program.
Vignesh Sunderrajan is a silicon design professional with 15 years of experience in implementing high-performance mobile, laptop, and networking chips, contributing to complex CPU and SoC programs from RTL to final layout at advanced technology nodes.
Related Content
- Relational physical design: no absolutes
- Accelerating Silicon Design for Physical AI
- Physical Design Flow Taps Partition Layout
- Current physical design tools come up short
- Exploring new design flows—physical layout
The post Why reliability metrics must dictate advanced-node physical implementation flow appeared first on EDN.
IronEar: the privacy-first audio sensor that recognises 500 sounds on-device
IronEar is an open source, privacy-first audio sensor that recognises more than 500 types of sound thanks to an AI running on board. The audio never leaves the device, so it never ends up on any server. The node is designed for the home and integrates with Home Assistant via MQTT. It can also communicate over LoRa when Wi-Fi is not available. That makes it an alternative to cameras for home surveillance, because it recognises the important sounds without compromising privacy.
The heart of the project is an Espressif ESP32-S3-WROOM-1 module with 16 MB of flash and 8 MB of PSRAM. This memory budget is what keeps the classification model and the audio buffers stored locally. The LoRa radio relies on a Semtech SX1262, while a Quectel LC76G completes the node’s feature set. The result is a self-contained sensor that does not depend on the home network to work.
Three MEMS microphones and the TinyEar classification modelSound capture is handled by three Infineon IM73D122 MEMS microphones, arranged in a triangular array. This geometry lets the node pick up sound from several points and handle directions of arrival better. Recognition, on the other hand, is handled by TinyEar, a port of Google’s YAMNet audio classification model. Classification happens locally about once per second, without recording audio or sending it to a server.
 The internal hardware of IronEar
The way it works comes down to a few steps:
- The three MEMS microphones pick up the sound of the environment.
- TinyEar classifies the sound locally about once per second.
- The result becomes a sensor event, with no audio stored.
- The node publishes it over MQTT to Home Assistant.
- If Wi-Fi is missing, the SX1262 module sends it over a Meshtastic channel.
The scene learning feature adds a useful layer in the home. The user records the sound characteristics of a room for a few minutes and the node then learns to recognise that particular acoustic scene. So it is not only good for telling one sharp sound apart, but also for understanding the state of an environment over time. Anyone who wants to rebuild the project will find the Crowd Supply campaign a starting point for understanding what is needed and how the node is put together.
MQTT on Home Assistant and a private Meshtastic channelFor home use, IronEar connects to Home Assistant through MQTT. That way a detected sound can be treated like any other sensor input, for example to turn on a light or send a notification. On top of that, the same event structure applies to all recognised sounds, so automations only have to be written once.
When Wi-Fi is not available, IronEar uses a LoRa module based on the Semtech SX1262 and communicates over a private Meshtastic channel. This is the part that makes the node interesting outside the home too, for example in a garage or an outbuilding. The sensor does not depend on local network coverage and keeps a low-power communication path open. All of it without ever letting the audio leave the device.
The numbers help frame the project. The ESP32-S3-WROOM-1 module provides 16 MB of flash and 8 MB of PSRAM. There are three Infineon IM73D122 MEMS microphones, arranged in a triangular array. IronEar recognises more than 500 different types of sound and classification happens locally about once per second. These figures explain why the node can work on its own, with no cloud and without recording anything.
For anyone who wants to rebuild the project, the software side relies on TinyEar and YAMNet for classification, on MQTT and Home Assistant for integration, and on Meshtastic for the LoRa channel. The hardware revolves around the ESP32-S3-WROOM-1, IM73D122, SX1262 and LC76G. The Crowd Supply campaign gathers the project and the details for anyone who wants to build it or follow it.
Source: https://www.crowdsupply.com/ironear-technologies/ironear
The post IronEar: the privacy-first audio sensor that recognises 500 sounds on-device appeared first on Open Electronics.
EEVblog 1784 - Claude Code Reverse Engineer 121GW Firmware SUCCESS!
Marvell to acquire Lumentum for $115bn, expanding total addressable market to $550bn
Cardiff and Swansea universities sign MoU to explore developing UK compound semiconductor pilot foundry capabilities
Blue Laser Fusion raises $34m in private placement
FLIP fluid simulator on a flip-dot display: Mitxela’s project
An electromechanical flip-dot display can become the surface of a real-time fluid simulator. That is what Tim Alex Jacobs, known online as Mitxela, did with a 13 by 28 dot panel. Every physical pixel flips according to the output of the FLIP simulation engine, and the fluid motion is controlled by a joystick that adjusts the direction of gravity. The flipping of the dots produces an audible sound, so the mechanical noise becomes part of the effect.
The software core is the two-dimensional FLIP fluid simulator by Matthias Muller. Jacobs had already used it two years earlier for a wearable LED pendant that imitated mercury under a sheet of glass. A flip-dot display is a form of dot-matrix bitmap in which physical indicators are flipped to show a dark or a light side. From a distance it forms a one-bit, single-colour image. Flip-dots also draw power only when they change state, which is why they are often used in public transport signage.
Custom driver circuitry and 50 ampere peaksJacobs replaced the original driver circuitry with a custom design, able to flip the dots faster for smoother motion. He also cut the boards to size so they could be placed side by side without seams. The high current demanded by the simultaneous flipping of the dots, up to about 50 amperes, is supplied by many small electrolytic capacitors scattered across the board. The display handles about 40 frames per second.
 The high current demanded by the simultaneous flipping of the dots is supplied by many small capacitors spread across the board.
The simulation input comes from a joystick that adjusts the direction of gravity to make the fluid move. In a hidden mode, an integrated inertial measurement unit lets you tilt the whole display to pour the fluid from one side to the other. The firmware runs on a Raspberry Pi Pico 2 W and on a ch32v003, with Python scripts to show test patterns and video through a USB-RS485 adapter.
Numbers, costs and what you need to rebuild itThe flip-dot panel has a resolution of 13 by 28. The full driver panels handle 13×8, while the ones at the ends are reduced to 13×4. The total cost of the large panel, excluding donor parts and Jacobs’s time, was under 500 pounds. Anyone who wants to rebuild it will find the firmware for the ch32, the Python scripts and the FLIP simulator in the Mitxela repository.
- Raspberry Pi Pico 2 W for running the simulation
- ch32v003 for the decode-sw firmware
- USB-RS485 adapter for the Python scripts
- Hanover flip-dot display 13×28
- Shift register for driving the dots
- Electrolytic capacitors for the current peaks
- Joystick for adjusting gravity
- Inertial measurement unit for the hidden mode
To send test patterns and video from a computer to the display you need a USB-RS485 adapter: a USB-RS485 converter does the same job.
Source: https://github.com/mitxela/flipdots
Related productsThe post FLIP fluid simulator on a flip-dot display: Mitxela’s project appeared first on Open Electronics.
Disassembling a SFP Ethernet adapter

If you need a spare RJ45 switch port but the built-in ones are all in use, don’t sweat it if you’ve got a spare SFP instead. Ethernet adapters can’t be beat, but (speaking of sweat) mind the heat.
My mid-September initial tutorial on small form-factor pluggable (SFP) modules covered their traditional interfaces to fiber optic cables, with subsequent single- and multimode module teardowns following in short order. It also looked at adapters enabling interface between a SFP cage and conventional Ethernet cabling.
Here’s an example adapter image from that post.

And here’s the relevant associated prose, with bolded emphasis for today’s thematic purposes:
RJ-45 modules mate the SFP or SFP+ circuitry to an Ethernet transceiver. Speeds up to 10 GbE, such as with the module shown at the top of this section, are widely available. These modules tend to run “hotter” than fiber optical or basic wire alternatives, all other factors being equal.
I also touched on the incremental heat dissipation of a module containing a SerDes-interfacing Ethernet transceiver versus one that more simply mates to an optical transmitter-plus-receiver combo (apparently in spite of the fact that the latter includes a laser) within a subsequent blog post that discussed the migration to multi-Gbit Ethernet equipment.
I’ve also seen some online commentary suggestive of high operating temperatures and associated questionable long-term reliability, particularly of the devices’ SFP+ subsystems [and double-particularly in conjunction with the use of SFP+ Ethernet adapters, I’ll add in arrears]. To at least some degree, this discussion is likely reflective of the switches’ fan-less designs.
And just last weekend I stumbled across another case study example of the high-temperature trend. I was reading up on reviews of USB- and Thunderbolt-to-Ethernet adapters, specifically various units from QNAP, both for further conceptual research purposes and in preparation for my own LAN migration plans. QNAP’s latest-generation adapters mate USB4 and Thunderbolt 4 to either 10G SFP+ or 10 GbE (and in both single-and dual-port forms); the prior-gen adapters I happened to be perusing at the time, the QNA-T310G1S (10G SFP+) and QNA-T310G1T (10 GbE), were Thunderbolt 3-based and single-port only.
Here are stock shots of both in sequential order.


Specifically, the reviews I was reading were from ServeTheHome and NASCompares; both conveniently included teardowns. But as I scrolled through them, I was initially confused. The text and pictures in the ServeTheHome piece both trumpeted a device that notably relied solely on only a passive heatsink, while those in NASCompares’ writeup highlighted a device containing a more sizeable heat plate accompanied by an attached active fan.


Match up the image to the associated color scheme (not to mention external port), however, and the seeming discrepancy will clear up in short order. ServeTheHome disassembled the 10G SFP+ version of the product family, whereas NASCompares went with the 10 GbE adapter.
Spec divergenceWith the QNAP devices as a representative case study, I’d therefore expect to see some further thermal dissipation assistance within today’s Ethernet-augmented dissection patient as compared to its optical-only predecessors—no room for a dedicated heatsink, presumably, nor even more certainly for a fan, but presumably at least some thermal paste and/or padding. But a further surprise awaited me even before I got inside.
Here’s the stock shot of what I thought I’d bought, as usual from Amazon’s Resale (formerly Warehouse) used-goods section: an Ipolex ASF-GE-T 10/100/1000BASE-T copper SFP to RJ45 transceiver with auto-negotiation support.

What Amazon shipped me instead, I learned, was the Ipolex ASF-2G-T. Although I didn’t realize this until it was in front of me, still in beat-up packaging, ready for teardown (not to mention beyond the retailer’s 30-day return “window”). As usual, it’s accompanied in the following photos (as well as other to follow) by a 0.75″ (19.1 mm) diameter U.S. penny for size comparison purposes.


My immediate deduction, as I’d unfortunately encountered no shortage of times before, was that someone had purchased a new Ipolex ASF-GE-T, swapped it for an ASF-2G-T already in their possession (still functional or not, not to mention authentic or not…who knows?) and returned the doppelgänger for full refund, with Amazon none the wiser as to the subterfuge it’d been the victim of…not to mention me, who’d then bought the stand-in. That said, while I likely still could have gotten my money back if I complained strongly enough, I didn’t much care in this instance. It had only cost me $8.50, and I was going to destructively (presumably) disassemble it anyway.
But bigger picture, why would someone even exchange a 2.5GbE ASF-2G-T for a 1 GbE ASF-GE-T? At first glance, the stand-in (assuming it’s still working, that is) is the seemingly superior option, at least from a bandwidth standpoint. My working theory neatly exemplifies a broader caution I’d already planned on passing along regarding adapters like these.
The Ipolex ASF-2G-T is no longer even listed on the supplier’s website, or anywhere elsewhere on the Internet (save for, maybe, the Internet Archive), for the matter—at least I wasn’t able to find it (let me know if you have better luck). But a more general Google search on the term “ASF-2G-T” reveals it’s still available for purchase from 10Gtek, an Iponex competitor.
Look closely at the specs and you’ll see that “2.5G” is the only data rate listed for 10Gtek’s version (and presumably also the Ipolex version) of the ASF-2G-T. In contrast, a different variant, the ASF-2G2-T, supports both 1G and 2.5G data rates. And the ASF-GE-T I thought I’d bought? It’s, again, a multi-rate “10/100/1000BASE-T copper SFP to RJ45 transceiver with auto-negotiation support”.
When evaluating SFP Ethernet adapters, keep in mind that they don’t necessarily support multiple possible data rates, for compatibility with whatever’s connected to the other end of the Ethernet cable, far from offering auto-negotiation handshaking capabilities (versus manual configuration, which necessitates the use of a managed switch).
Retention implementation deviationBefore trying to figure out how to get underneath the Ethernet adapter’s metal enclosure, I’ll first share the rest of the exterior shots.
Right side, as before with “right” referencing its orientation when inserted in a network switch or other gear’s SFP port.

Bottom. As before, note the retaining pin, although this time it’s not retractable.

Instead, in this case, rotating the “lock” mechanism lever in the front of the module moves a “ramp” into position adjacent to the pin, enabling you to then slide the module out of the cage.


Left side.

Back to the RJ45 connector for the more traditional right-side-up and upside-down views.


And the same goes for the SFP connector on the other end.


Now to get inside. First step; peel away the topside sticker and see if there’s a screw head underneath. Nope.


Past modules had small inward-bent pins on the sides that, when coaxed back out of the enclosure, enabled the two halves to then slide apart. This time, the “extra” metal pieces were more sizeable and looked more like cage-retention “springs”, but I tried anyway. Again, nope.

Finally, giving the assemblage one final frustrated look-over, I belated noticed two small retention pins alongside the SFP connector.

Like the rest of the case, they were made of sturdy stuff, but I eventually “sprung” them both.

As prognosticated beforehand, there’s the thermal pad. The first of several? Hold that thought.

It originally covered both ICs on the right half of the PCB topside, as the slight indent matching the shape of IC U7 reveals. The plastic shell surrounding the SMD-packaged LAN transformer on the PCB’s left side got mangled by yours truly while wrenching the topside metal piece away.

Now how to get the PCB the rest of the way out? First remove the lock mechanism, mebbe?


Bingo (top view of the PCB extraction process first, then bottom).


Leaving behind yet another, smaller thermal pad.

Let’s look again at the comparatively boring RJ45 and SFP ends first, first right side up and then upside down in both cases.


Now for the perspectives you all really care about. This (top) side you’ve previously sorta-seen already, in encumbered-by-assembly form.

The LAN transformer is the AE-SE24203 from Apps Electronics. To its right (I hope you’ll take my word for it given the faint markings) is the primary thermal pad rationalization, Motorcomm’s YT8821C single-port, 2.5 GbE physical layer (PHY) transceiver. And to its right, past the inductor intermediary, is the aforementioned U7, in a diminutive five-lead package (which always leads me to suspect a dual-transistor structure inside) and faintly mixed-case labeled as follows (readers?):
JWQZY
4y6eE
Now for the other side (both flipped and rotated; note that the RJ45 is now on the right).

Passives dominate the landscape this time. At far left is a three-lead (single transistor?) packaged device labeled as follows (with the last digit 90° rotated versus the others).
P5S4
To its right is the much larger IC originally with the smaller thermal pad atop it and labeled as follows (first three lines):
F330GB
F107079
PJ2423
Those three lines’ worth of characters weren’t in and of themselves terribly helpful from a Google search standpoint, but the last line was more enlightening (at least in theory):
GD ARM
My suspicion is that the first two characters reference the vendor GigaDevice, with the other three indicating an Arm architecture SoC, and that we’re therefore looking at a GD32F330-family offering based on the Cortex-M4 and containing up to up 128 Kbytes of flash memory and 16 KBytes of SRAM, along with a host of peripherals. The family is spec’d to run up to 84 MHz but, considering the 25 MHz crystal further to the right, is seemingly underclocked to its peak potential. Thermal management, don’cha know.
That’s all I have for you today, folks. As always, sound off with your thoughts in the comments!
—Brian Dipert is the associate editor, as well as a contributing editor, at EDN.
Related Content
- SFP: Add-in module delivers diminutive performance and flexibility
- SFP: The single-mode module autopsy
- SFP: The multimode module autopsy
- The multi-gig Ethernet migration: Motivations and implementations
- Design considerations in high-speed fiber networks
The post Disassembling a SFP Ethernet adapter appeared first on EDN.
STMicroelectronics Introduces Automotive Safety Combination Sensors for Mass-Market Applications
STMicroelectronics has announced a set of automotive sensors that enable vehicle brands to extend advanced safety and driver-assistance features across categories from premium to mass-market, broadening access to state-of-the-art protection.
Combining multi-axis accelerometers and gyroscopes (angular rate sensors) in a single package, ST’s new sensors offer a unified platform for OEMs and Tier-1 suppliers to build active and passive safety systems that meet stringent automotive quality, reliability, and safety requirements. The devices address use-cases ranging from crash protection, rollover detection, and airbag deployment to vehicle stability controls and radar beam stabilization.
These are the first products launched in the mass market following ST’s acquisition of the NXP automotive and industrial MEMS sensors business in early 2026, a move completed to expand its own MEMS sensors capabilities. ST’s experience in automotive sensing reflects its commitment to guaranteeing product availability for at least 15 years, allowing companies to minimize lifecycle and redesign risks while investing confidently in new programs.
“As a cohesive sensor set suited to multiple safety functions, these devices simplify system architecture, accelerate development, and increase flexibility to scale features and performance,” said Simone Ferri, Executive Vice President, MEMS Sub-Group, STMicroelectronics. “Strengthened by our longevity commitment and global support infrastructure, these are the first automotive safety combination sensors ready for mass-market deployment, accelerating the move to active safety.”
Omdia has commented on the market opportunities for inertial sensing in Advanced Driver Assistance Systems (ADAS). Nora Houlihan, Senior Research Analyst at Omdia, said, “Thanks to ADAS, inertial measurement units (IMUs) are expected to grow at 17.7% CAGR (2025-30). As automotive manufacturers approach higher levels of autonomy there will be a significant increase in IMU-powered MEMS sensors for acceleration and motion detection.”
Automotive Combination Sensors from STMicroelectronics: Technical InformationST’s combination sensors integrate a multi-axis accelerometer and gyroscope in a single ISO 26262 compliant device with full internal diagnostics. All sensors support SafeSPI, the standard serial peripheral interface for automotive safety, that enables independent monitoring of sensor data.
The new sensors comprise:
- NCS1012BAEP, with z-axis (yaw) angular rate sensor and xy low g acceleration sensor.
- NCS1012CAEP, with x-axis (roll) angular rate sensor and yz low g acceleration sensor.
- NCS1012EAEP, with x-axis (roll) angular rate sensor and xy medium g acceleration sensor.
- NCS10135AEP with z-axis (yaw) angular rate sensor and xyz low g acceleration sensor.
The integrated angular rate sensors have a full-scale range of ±125 dps, ±250 dps or ±350 dps and feature low offset with minimal drift over the automotive temperature range (−40°C to +105°C). A low-pass filter is integrated, with 3dB frequency options of 12.5Hz to 400Hz, as well as an optional single-pole high-pass filter with fast startup.
The low g acceleration sensors feature a nominal full-scale range from ±1.50 g to ±34 g, while the medium g acceleration sensors have nominal full-scale range from ±15.5 g to ±150 g. These feature an independent signal chain to minimize noise, low offset with low drift over the automotive temperature range, and an integrated low-pass filter. The four new sensors are in production now, in 24-pin QFN 6mm x 6mm x 1.90mm packages, with wettable flanks meeting automotive-industry optical inspection compatibility requirements.
The post STMicroelectronics Introduces Automotive Safety Combination Sensors for Mass-Market Applications appeared first on ELE Times.
Aratas Corporation: A New Era for OMRON Components
Aratas Corporation, headquartered in Kyoto, Japan, began operations today with a new management structure, following completion of the planned share transfer. Led by President and CEO Masahiko Ezaki, Aratas was established on 1 July 2026 through the spin-off of OMRON‘s Device & Module Solutions (DMS) business. It now operates within a strategic partnership with Carlyle.
A new chapter for OMRON electronic componentsFor European customers, Aratas combines reliability and innovation. It carries forward more than 90 years of OMRON tradition, including decades of Japanese excellence in design and manufacturing, proven product reliability and supply chain security. The established European team remains in place, preserving product expertise, customer support, local presence and distributor relationships. Thanks to its specific focus on switching, connection and sensing technologies, Aratas can respond more quickly to evolving customer needs and better align development and investment with their priorities.
 The Aratas headquarters, the new company created on 1 July 2026 from the spin-off of OMRON’s Device & Module Solutions business.
The Aratas portfolio of relays, switches, connectors and sensors supports the safe and reliable operation of mission-critical systems through power switching, control, connectivity and sensing functions. The global growth strategy focuses on markets such as energy management, mobility, digital infrastructure and smart automation. Beyond its established business, Aratas will explore medium- to long-term opportunities in sectors such as medical, aviation and space, where new societal needs could create new applications for its technologies.
Focus on EuropeIn Europe, Aratas is pursuing this strategy by focusing on key areas such as high-power electrification, grid-scale energy storage and high-frequency domain testing, including automated test equipment (ATE) for semiconductors. The company combines product expertise, regional support and supply security to help original equipment manufacturers (OEMs), electronics manufacturing services (EMS) providers, distributors and other customers move faster from system design to qualification and production.
Statement from José Luis González del Val«European manufacturers must reconcile shorter development cycles with stricter regulations, growing sustainability requirements and greater supply chain risks», said José Luis González del Val, Chief Operating Officer of Aratas Europe. «Component performance is only part of the answer. Supply continuity, verifiable product data and practical support for certification and qualification are just as important. The transition to Aratas carries this guarantee forward while adding greater focus and agility. Together, these strengths are essential to achieving our ambition of becoming the partner of choice wherever component selection directly affects system performance, risk control and business results.»
The meaning of the name AratasThe name Aratas combines two Japanese words meaning «new» and «tomorrow» and reflects the company’s mission to foster innovative connections between people and technology to create a new tomorrow. The values Aspire, Agile and Ahead define how the company will pursue this mission, while the motto Always New, Always Electric expresses its forward-looking orientation.
For more information, visit Aratas.com.
The post Aratas Corporation: A New Era for OMRON Components appeared first on Open Electronics.
Smartphone shipments fall 20% year-on-year in Q3, the lowest third-quarter total since 2013
NUBURU regains compliance with NYSE American continued listing standards
Pocket Pico: a terminal node controller for amateur packet radio
The Pocket Pico is a terminal node controller for amateur packet radio, a modern rebuild of the Heathkit HK-21 Pocket Packet. Inside sits a Raspberry Pi Pico, and the firmware is the same as the original machine’s. So anyone who builds one steps into packet radio with current hardware, yet keeps compatibility with historic software.
The project is by btech. Anyone who wants to rebuild it will find the full write-up on the project page on btech’s site, with the design choices and the construction details.
A Z80 emulator inside the Raspberry Pi PicoThe trick is emulation. The Raspberry Pi Pico runs a Z80 processor emulator, and that lets it run the original Heathkit HK-21 firmware. Instead of rewriting the terminal node controller logic from scratch, the project reuses code that already worked forty years ago.
The microcontroller does not limit itself to playing the part of the CPU. It also handles modulating and demodulating the Bell 202 audio tones, so no dedicated modem chip is needed. The transmission speed of the Bell 202 tones is 1200 baud.
- Raspberry Pi Pico as the only control board
- Z80 processor emulator to run the HK-21 firmware
- Bell 202 tone modulation and demodulation at 1200 baud with no dedicated modem chip
- APRS and AX.25 Level 2 handled by the firmware
- Built-in Personal Bulletin Board System for messages from other stations
On the radio side the device handles APRS and AX.25 Level 2. It also includes a built-in Personal Bulletin Board System, meaning it lets other stations leave messages on your own. That is the feature that, in the original HK-21, made the Pocket Packet a real node and not just an interface.
Thanks to using the same firmware as the HK-21, the Pocket Pico stays compatible with a lot of dated packet radio software. So anyone with old packet programs at home does not have to start over.
What you need to rebuild the Pocket PicoThe shopping list is short. You need a Raspberry Pi Pico, the original Heathkit HK-21 firmware and the Z80 processor emulator. Then you need the audio connection to the radio, which is the part where the build needs the most care.
The Pico acts as emulated CPU and modem together, so there are no other chips to solder for the modulation side. This reduces the failure points and simplifies the board. However, setting the audio levels to the transceiver remains the critical step: if the tones come in too strong or too weak, the 1200 baud demodulator will not lock on.
The project also has a video, so anyone who prefers to see the machine working before soldering will find the footage shot by btech. In short: a Pico, a 1983 firmware and a bit of care with the audio are enough to get into amateur packet radio with a modern node.
Source: https://n7wdz.com/project-pocket-pico-tnc.html
The post Pocket Pico: a terminal node controller for amateur packet radio appeared first on Open Electronics.
Rohde & Schwarz’s MXO AI Connect: AI-assisted Intelligence for Oscilloscope Workflows
Rohde & Schwarz connects AI assistants to its MXO oscilloscopes through MXO AI Connect. The new software adds natural language interaction, instrument-specific guidance and automation support to oscilloscope workflows in the engineer’s preferred AI environment. With the new MXO AI Connect, Rohde & Schwarz brings AI-assisted instrument intelligence to its MXO oscilloscopes. Engineers can use natural language to describe a task, while the connected AI assistant draws on instrument-specific knowledge to map that request to oscilloscope functions and actions.
Modern test environments combine complex measurements, broad instrument functionality and growing automation requirements. MXO AI Connect links the reasoning capabilities of the user’s chosen AI model with trusted, instrument-specific knowledge from Rohde & Schwarz. This helps the assistant understand the user’s intent, determine how a requested task can be carried out on the oscilloscope and interact with the connected instrument. In this way, the software extends the instrument workflow beyond remote control by combining natural language interaction, technical knowledge and execution.
MXO AI Connect supports all models of the MXO 3, MXO 4, MXO 5 and MXO 5C oscilloscope series, and R&S ScopeStudio. It is a locally installed Model Context Protocol (MCP) server that runs on a user’s PC or on a shared lab host. No additional software is required on the instrument. Engineers can choose their preferred AI client such as Cursor, Claude Desktop, Claude Code and GitHub Copilot, along with their preferred large language model and data handling policy.
The server provides access to model-specific MXO help content and communicates with the instrument through standard VISA connections such as HiSLIP, VXI-11 or TCP/IP, keeping instrument communication within the local environment. Front-panel operation remains available while the AI assistant is connected.
Typical AI-assisted Workflows with MXO AI ConnectUnderstanding: Engineers can bring instrument-specific knowledge, documentation and application guidance directly into their workflow to support learning and day-to-day work with the oscilloscope.
Configuration: Natural language requests can be translated into the appropriate instrument functions, settings and automation approaches, which can reduce setup and implementation effort and limit the need to search through documentation or coding examples manually.
Analysis: The reasoning and data processing capabilities of modern AI models can support the review of measurement results, the identification of waveform characteristics and the assessment of relationships or behaviour in the data.
Automation: For more complex tasks, AI agents can coordinate instrument control, analysis methods and software automation across broader test workflows, with repeated adjustments to setups and code until the intended measurement objective is reached.
Philip Diegmann, Vice President Digital & Power Test Solutions at Rohde & Schwarz, says: “AI offers engineers a new way to work with increasingly capable test instruments. With MXO AI Connect, they can move more quickly from a measurement task to the right instrument setup and from there to analysis and automation. This makes it easier to work with complex instrument functions and integrate them into broader test workflows.”
The post Rohde & Schwarz’s MXO AI Connect: AI-assisted Intelligence for Oscilloscope Workflows appeared first on ELE Times.
MicroVision Collaborates with FieldAI to Deploy Next-Generation Autonomous Capabilities
MicroVision has announced an expanded collaboration with FieldAI, a developer of autonomous robotic systems for government and industrial applications. The collaboration builds on successful testing of MicroVision’s perception technologies by FieldAI’s Federal team, including evaluation of the IRIS long-range lidar sensor on autonomous ground vehicles and demonstrations of MicroVision’s extended perception solution.
The partnership combines the Robinson Unmanned Spirit drone platform with the MOVIA Air Plus sensor for real-time, colorized 3D lidar mapping integrated with ATAK. In addition, FieldAI has purchased MicroVision MOVIA sensors for development and evaluation activities spanning both government and industrial autonomous robotics initiatives.
MicroVision & FieldAI: Advancing Autonomous Capabilities“FieldAI is pioneering autonomous systems designed for some of the most demanding operational environments, and we’re excited to continue expanding our collaboration across both their Federal and Industrial organizations,” said Glen DeVos, CEO of MicroVision. “From long-range perception for autonomous ground vehicles to real-time 3D mapping and short-range obstacle detection, our portfolio provides the flexibility and performance required to support next-generation robotic systems. We look forward to supporting FieldAI as they continue advancing autonomy across commercial and government applications.”
“The performance and versatility of MicroVision’s sensing technologies have made them an important collaborator as we continue advancing autonomous capabilities across our platform portfolio,” said Shehryar Khattak, Director of Technology at FieldAI. “Following successful tests across uncrewed ground and aerial systems, we are expanding our evaluation efforts to identify opportunities for broader adoption of MicroVision’s perception solutions across both our Federal and Industrial programs.”
The collaboration reflects growing demand for advanced perception solutions capable of supporting autonomous mobility, navigation, mapping, obstacle detection, and mission execution across government and industrial robotic platforms. By combining MicroVision’s portfolio of long-range, short-range, and aerial perception solutions with FieldAI’s autonomy software and robotic systems expertise, the companies are exploring opportunities to accelerate the deployment of next-generation autonomous capabilities in challenging operational environments.
The post MicroVision Collaborates with FieldAI to Deploy Next-Generation Autonomous Capabilities appeared first on ELE Times.
Ground penetrating radar: How RF waves map the unseen world

Beneath every road, field, or foundation lies a hidden story of layers and boundaries. Engineers, archaeologists, and surveyors have long sought ways to uncover these subsurface details without disturbing the ground itself.
That’s where ground penetrating radar (GPR) steps in, an elegant blend of physics and practicality, turning invisible transitions beneath our feet into readable signals.
GPR isn’t a magical “x‑ray vision for the ground”—it’s far more precise. Think of it as an RF boundary‑detector, a tool that listens for echoes not in sound but in electromagnetic waves. Just as a shout in an alleyway bounces back when it strikes a wall, GPR pulses return when they encounter a shift in material properties beneath the surface.
The key is that GPR doesn’t reflect off objects themselves; it responds to dielectric discontinuities—the invisible boundaries where one material’s permittivity changes to another, revealing hidden layers and structures without ever breaking the ground.
The physics of wave travel
At the heart of GPR lies the concept of dielectric permittivity—a property that tells us how easily a material allows electromagnetic fields to pass through. Different soils, rocks, and man‑made materials each have their own relative permittivity, and this directly controls how fast radar waves move within them.
In simple terms, the higher the permittivity, the slower the wave travels. This change in speed is what creates the echoes GPR listens for, turning invisible boundaries underground into detectable signals.

Figure 1 See the Radiodetection LMX200 GPR system equipped with a high-resolution display screen and integrated GPS antenna. Source: Sensors & Software
As a quick aside, integrating GPS into GPR systems transforms isolated subsurface radar profiles into precise, geographically-referenced 3D spatial models by linking every emitted radar pulse directly to real-world latitude, longitude, and elevation coordinates. While traditional GPR setups rely on mechanical measuring wheels that are prone to slippage and drift on rough terrain, high-precision GPS—particularly real-time kinematic (RTK) systems—enables survey teams to walk or drive freeform paths without painting manual grid lines on the ground.
That automatically corrects radar depth profiles for uneven ground topography and allows operators to export exact utility locations directly into GIS, CAD, or Google Earth for accurate long-term relocation and excavation safety.
Materials and their echoes
Different ground materials shape radar signals in strikingly different ways. Air offers almost no resistance, so waves travel at full speed. Dry soil or concrete slows them moderately, with values that vary depending on density and composition.
Water, however, is a dramatic case; its high permittivity means radar waves crawl through it, creating strong reflections and explaining why wet soil can overwhelm a survey. And when waves meet metal, the contrast is so extreme that the signal is completely reflected, producing a sharp boundary echo.
Choosing the right frequency is a balancing act. High‑frequency radar (in the gigahertz range) delivers fine detail, capable of spotting millimeter‑scale features, perfect for scanning rebar in concrete or mapping shallow structures. But those same waves are quickly absorbed, limiting penetration to less than a meter.
Low‑frequency radar, on the other hand, can reach tens of meters into the ground, revealing large formations like bedrock layers. The trade‑off is resolution: small pipes or fine details blur away, leaving only the bigger picture.
Hardware architecture and RF front‑end
An impulse GPR system is built around a few critical segments, each designed to handle the unique challenges of probing beneath the surface.
- Transmitter: At the front-end, the transmitter fires sub‑nanosecond, high‑voltage pulses into an ultrawideband antenna, often bow‑tie or tapered slot designs. The challenge here is pulse purity: any “ringing” or lingering oscillation can blur the radar’s timing, so engineers work hard to shape clean, sharp impulses.
- Receiver: On the other side, the receiver must be remarkably versatile. Soil attenuation is exponential, meaning shallow reflections can be overwhelmingly strong while deep echoes may arrive as faint microvolt signals. A high‑dynamic‑range front‑end ensures both extremes are captured without distortion.
- Time‑domain sampling: Capturing these fleeting pulses requires clever timing. Techniques like equivalent time sampling (ETS) allow picosecond‑scale events to be reconstructed using manageable hardware budgets, while high‑speed ADCs paired with MCUs or DSPs provide direct digitization for modern designs.
- Frequency domain (SFCW): Not all GPR systems rely on impulses. Stepped‑frequency continuous wave (SFCW) radar takes a different approach, sweeping through frequencies with direct digital synthesizers (DDS). While impulse systems excel at sharp time resolution, SFCW offers fine frequency control and can be easier to process digitally, making it a strong alternative in certain applications.
Data and signal processing: Why everything looks like a hyperbola
GPR data begins with the A‑scan, a single trace of signal amplitude versus time delay at one position, and expands into the B‑scan, where multiple A‑scans are stacked as the antenna moves to form a two‑dimensional cross‑section. Within these B‑scans, point targets such as buried pipes consistently appear as upside‑down hyperbolas.
This familiar curve isn’t a flaw but the natural result of geometry: as the antenna approaches the target, the travel path shortens; directly above it, the path is at its minimum; and as the antenna moves past, the path lengthens again. The changing slant‑range distance produces the hyperbolic signature that surveyors rely on to distinguish compact objects from broader subsurface layers.

Figure 2 Line scan GPR display showing signal amplitude versus depth and position. Conical radar emission creates a characteristic hyperbolic reflection for point targets (pipes, rocks, roots) with the target’s true location marked by the apex of the hyperbola. Source: Author
Practical engineering takeaway and workbench experiment
Modern radar technology has become accessible enough that even hobbyists and bench engineers can explore its principles. Compact ultrawideband (UWB) radar chips, low‑cost vector network analyzer modules like the NanoVNA, and software‑defined radios (SDRs) make it possible to experiment with frequency‑modulated continuous wave (FMCW) or stepped‑frequency continuous wave (SFCW) radar on a workbench. These tools allow hands‑on exploration of how signals reflect, attenuate, and reveal boundaries—without the need for industrial‑scale equipment.

Figure 3 VNA6000 (NanoVNA V3) delivers two-port 6 GHz vector network analyzer performance comparable to higher-end professional instruments in a small, portable form factor. Source: NanoRFE
But GPR isn’t invincible. Certain ground conditions can break its effectiveness. High clay content soils absorb signals aggressively, saltwater intrusion creates strong conductive losses, and hyper‑conductive soils scatter energy so severely that useful echoes vanish. These edge cases remind engineers that while GPR is powerful, its success depends on the physics of the medium it probes.
Beyond the basics
A few practical realities complete the picture for engineers working with GPR. Antenna choice is critical: ground‑coupled designs dig deeper into the soil, while air‑coupled antennas favor resolution and portability. Calibration and clutter removal—through baseline subtraction and background filtering—help suppress system ringing and surface noise.
Modern systems also extend beyond simple B‑scans, building C‑scans or even full 3D reconstructions with migration algorithms. Because GPR operates in ultrawideband ranges, spectrum regulations and licensing must be considered before deployment.
In the field, sensor fusion is common, with GPS adding georeferencing and magnetometers to provide complementary subsurface data. And interpretation always demands caution: tree roots, voids, or soil heterogeneity can mimic hyperbolic signatures, reminding us that while GPR is powerful, its results must be read with care.
GPR reminds us that the world beneath our feet is full of hidden boundaries waiting to be revealed. From professional surveyors mapping infrastructure to hobbyists experimenting with SDRs on a workbench, the same principles of echoes and discontinuities apply. The challenge is real—wet soils, clays, and conductive layers can frustrate even the best systems—but the opportunity is greater: to explore, to innovate, and to make the invisible visible.
Well, whether you’re an engineer, a student, or simply curious, take the next step. Try a bench‑scale experiment, dive into open‑source SDR projects, or look at your environment with new eyes. GPR isn’t just about scanning the ground; it’s about cultivating the mindset to uncover what lies beneath.
 T. K. Hareendran is a self-taught electronics enthusiast with a strong passion for innovative circuit design and hands-on technology. He develops both experimental and practical electronic projects, documenting and sharing his work to support fellow tinkerers and learners. Beyond the workbench, he dedicates time to technical writing and hardware evaluations to contribute meaningfully to the maker community.
Related Content
- Radar Essentials
- Ultrawideband radar system design
- Radar Basics: Range, Pulse, Frequency, and More
- Challenges in designing automotive radar systems
- 3-D radar data-capture innovation makes IEDs easier to spot
The post Ground penetrating radar: How RF waves map the unseen world appeared first on EDN.
Сторінки